LAB NEWS.
Papers, visits, field tests, and everything else happening in the lab.
In the press
-
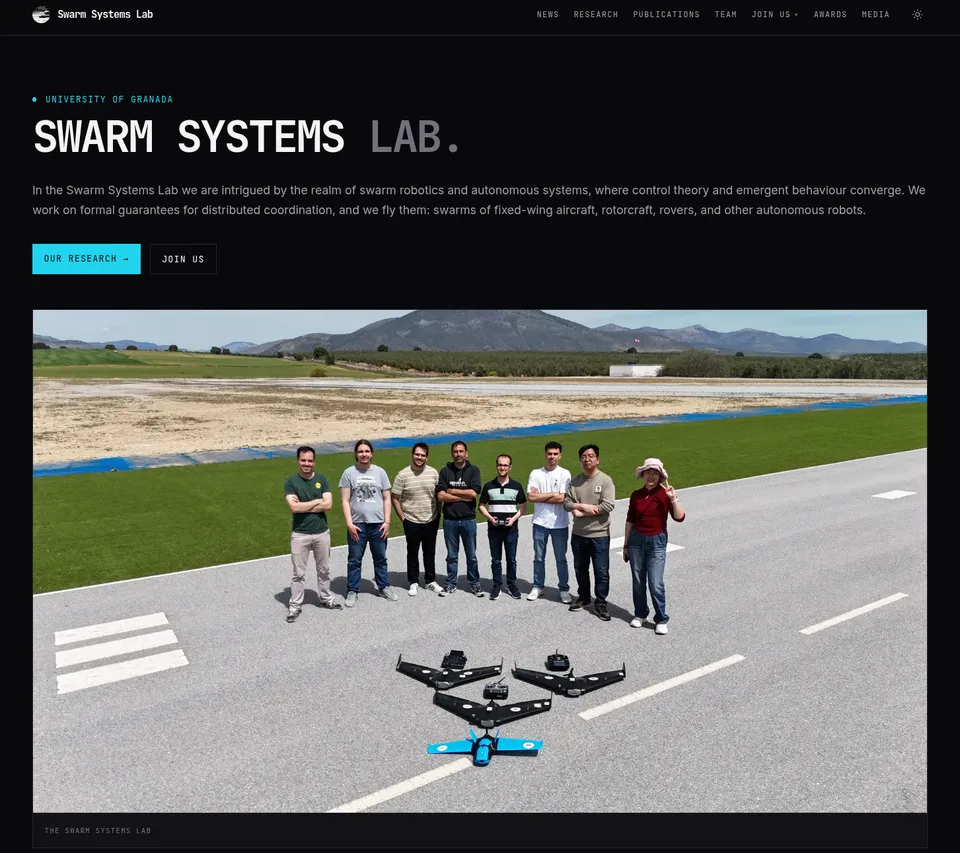
Welcome to our new website!
After years on Google Sites we have rebuilt it from scratch. The old one had served its purpose, but it had grown rusty: slow to load, awkward to lay out, and enough of a chore to update that news tended to pile up…
-
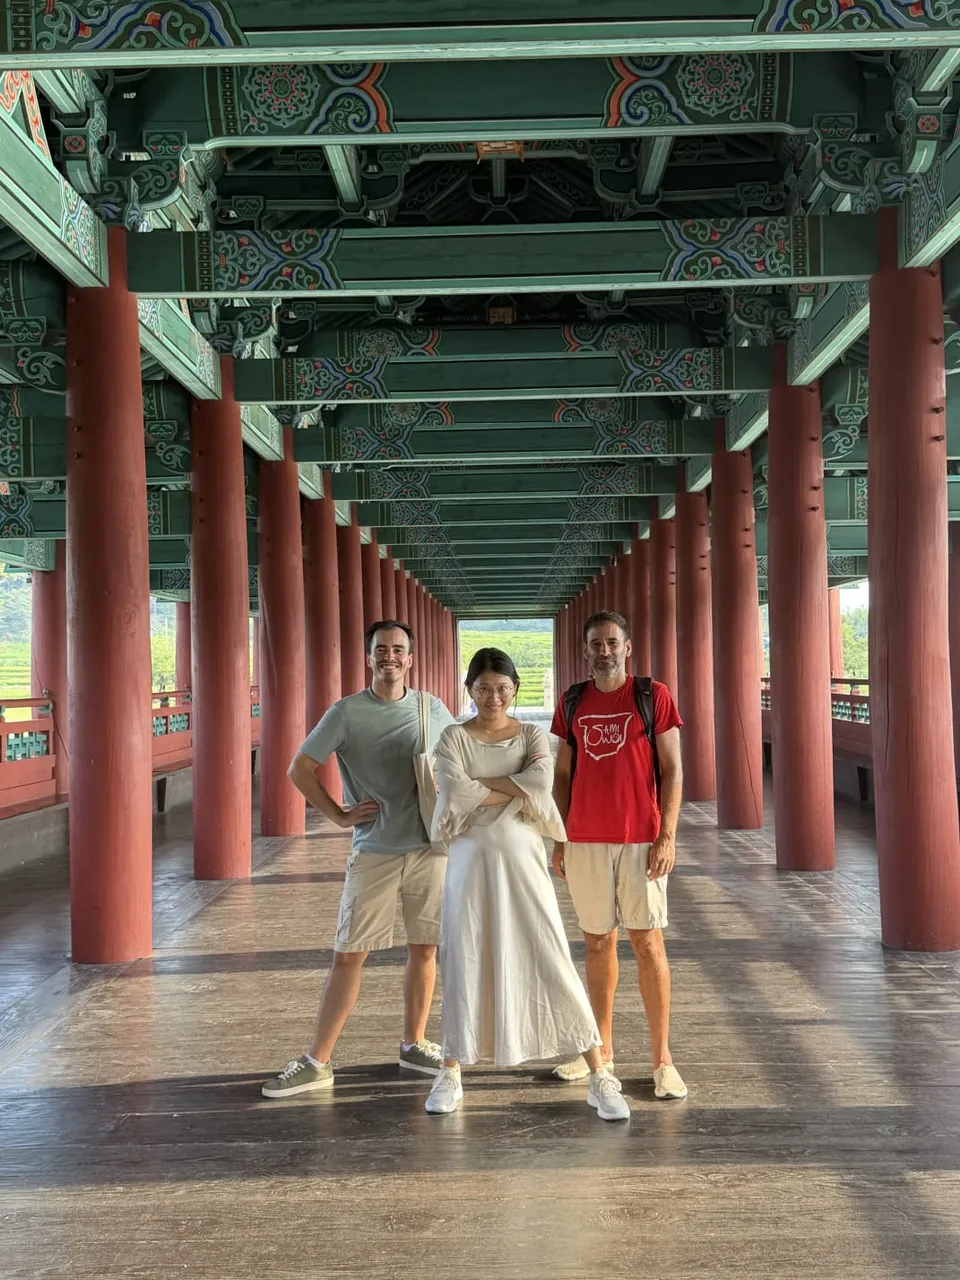
Time to go home!
What an Asian tour this time. The Swarm Systems Lab represented by Jingy, Jesús, and Héctor, were visiting the Shanghai Jiao Tong University, the University of Hunan and the 2026 IFAC World Congress in Busan, presenting…
-
Our more-than-two-years work on source seeking got accepted in the IEEE Transactions on Automatic Control!
It started as a bachelor thesis and it rapidly got out of hands. Thanks to Antonio Acuaviva, Jesús Bautista, José Hinojosa, Weijia Yao, and Juanfran!
-
Two papers accepted in multi-robot systems!
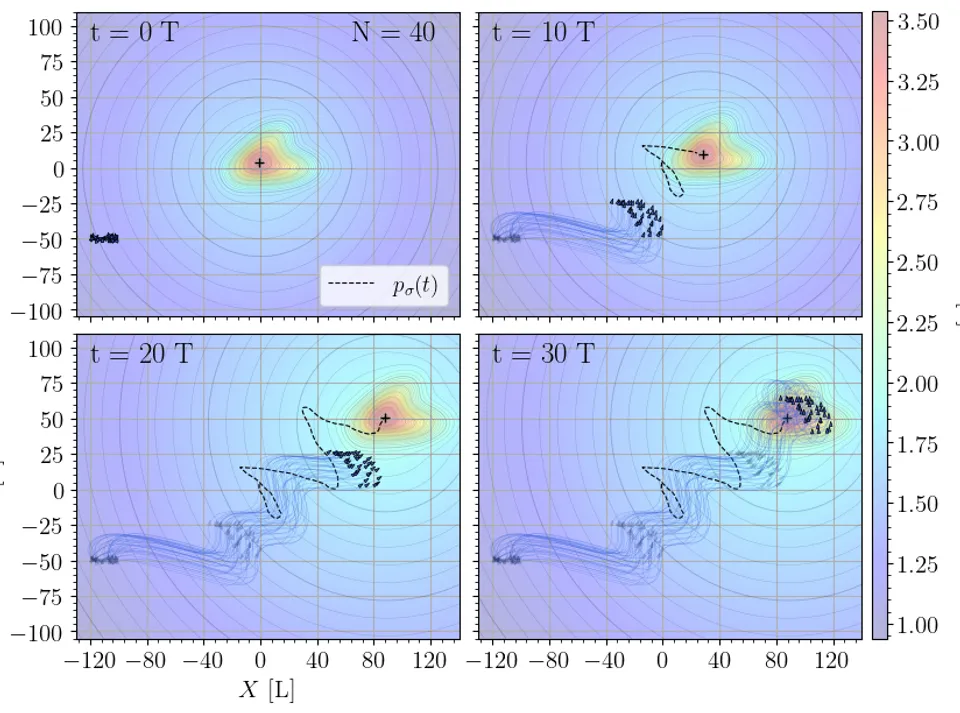
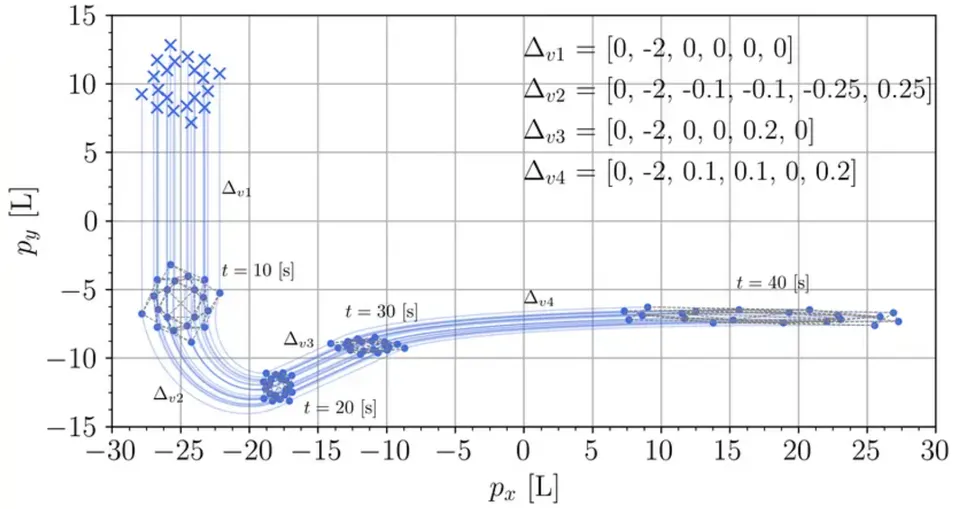
The first first-author paper for one of our PhD Students of the group, Jesús Bautista. It is titled Leaderless Collective Motion in Affine Formation Control over the Complex Plane and it has an elegant formulation and…
-
New video from the lab
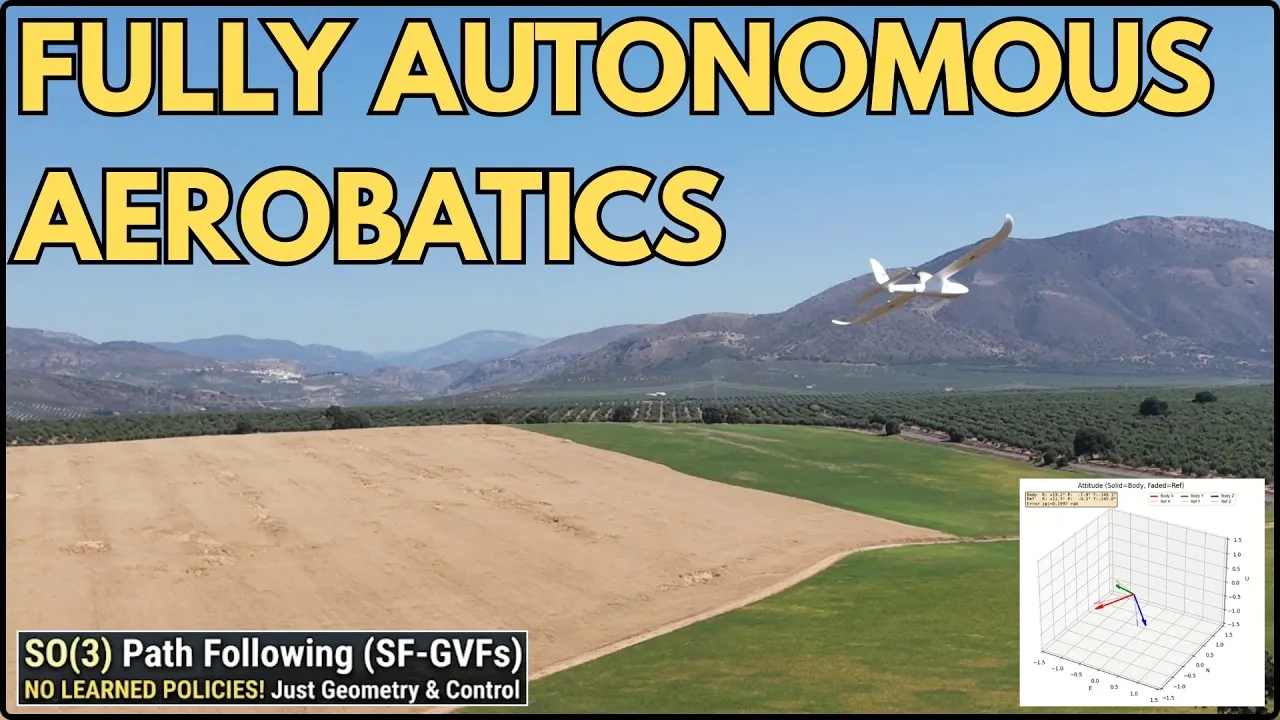
This time showing aerobatics with a fixed-wing drone. No GPS is involved and all the maneuvers are fully autonomous. In fact, we can concatenate and superpose them!
-
The Andalusian TV has made a short (5 min) cover of our ERC Aerosense project :P
The Andalusian TV has made a short (5 min) cover of our ERC Aerosense project :P. It has a good edition. Aerosense is an ERC Proof of Conceptseeking to give spatial awareness employing only distributed and local…
-
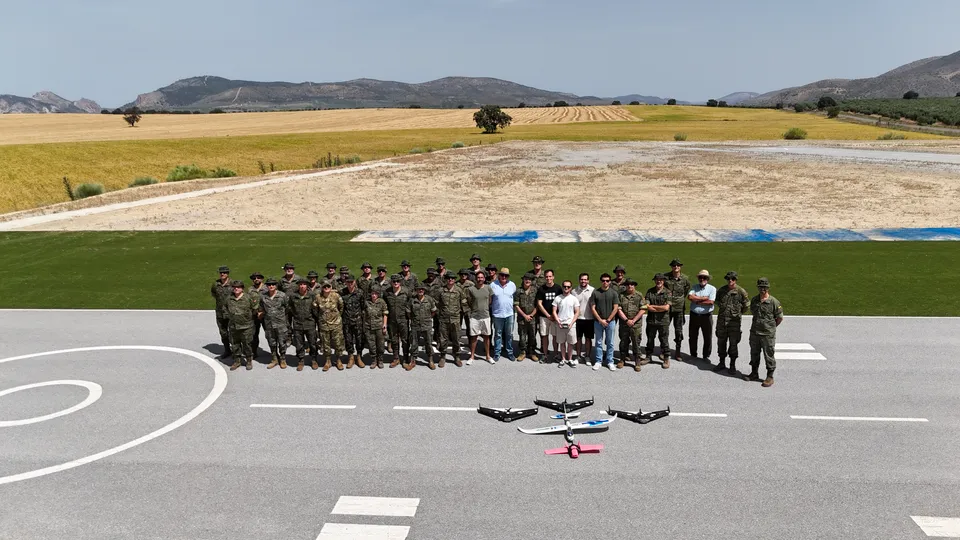
Today, we demonstrated our drone technology to a delegation from the Spanish Army, including two generals
Although our research is not military in nature, we recognize the growing importance of drone technology for national security. During the visit, we shared our expertise with MADOC, the branch responsible for…
-
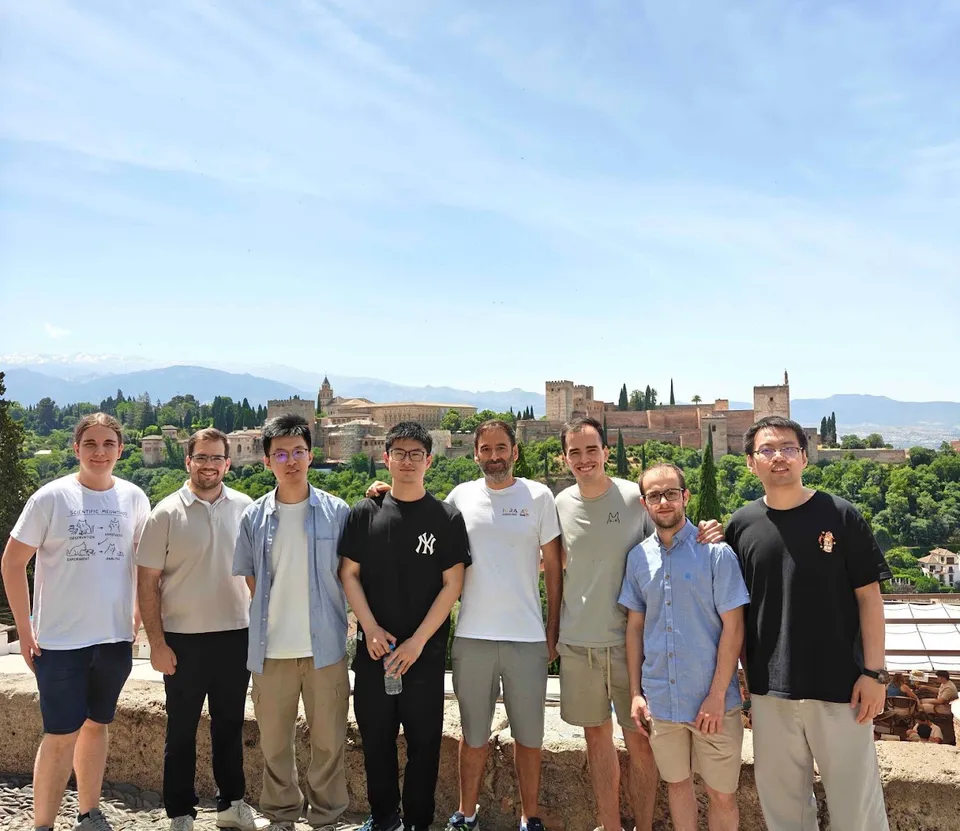
Today we had visitors from Westlake University, China
Zirui Chen and Zhanyu Guo were showing us their latest work on following clouds of points as "diffusive paths" and aerobatics with rotorcraft. Thanks a lot for sharing your research with us!
-
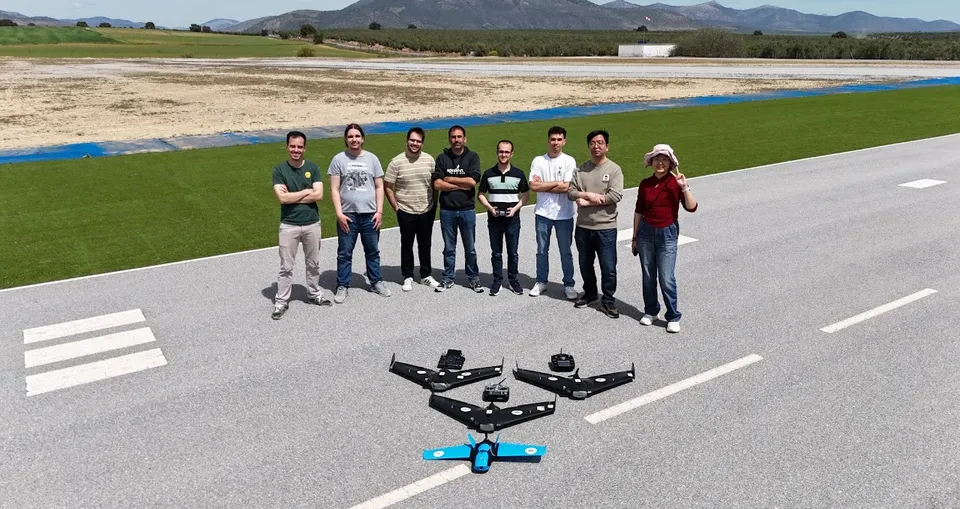
New group photo:)
New group photo :). Our 3D printed drones start to take over the traditional foam ones in our weekly flights. We also had two accepted papers to IFAC World Congress!
-
The University of Granada has interviewed us!
It's about our ERC Aerosense project. We are also in the news. Check the articles in IDEAL and CANAL UGR.
-
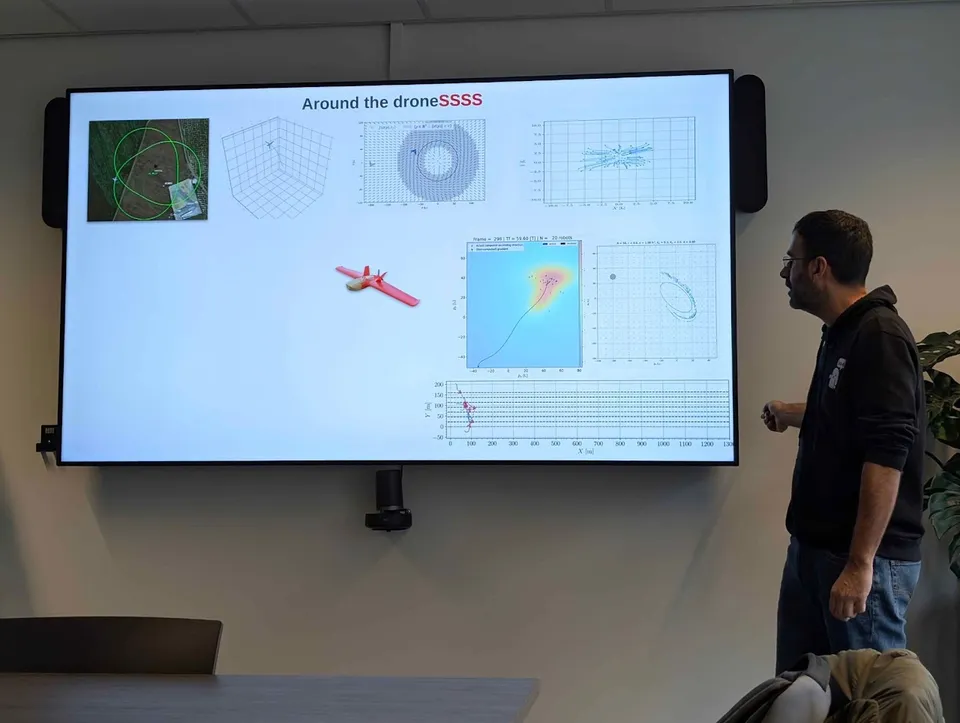
Jesús and Héctor were giving a talk in TU-Delft about our latest developments in multi-agent and drone systems
Thanks a lot to Javier Alonso-Mora and his group for the opportunity!
-
Binbin was visiting our group during this week
He is a postdoc from the University of Groningen. We are definitively engaged on how agents, in a purely reactive way, can tag themselves in formation control problems. Thanks a lot for your visit!
-
Hector was giving a seminar on how heterogeneous imperfections on actuation and sensing impact on consensus algorithms
The seminar was titled Consensus Protocols under Shifted Actuation and Sensing, and was hosted by Lara Briñón at GIPSA Lab in Grenoble, France.
-
We have a visitor!
Michael Epp, a Ph.D. student from the TU Berlin will be with us for at least three months. His interests are also in control theory for multi-agent systems.
-
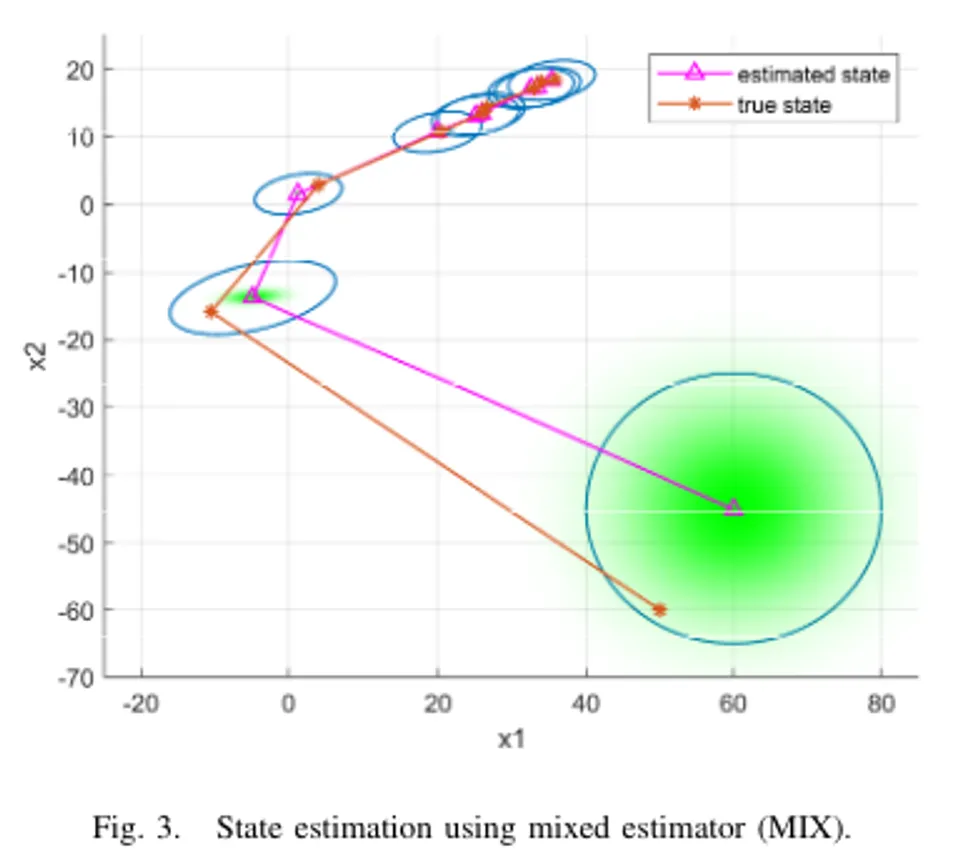
We have an interesting paper accepted in the American Control Conference titled Linear quadratic control for discrete-time systems with stochastic and bounded noises led by the postdoc Xuehui Ma
In this work, we show for the first time how to handle stochastic noise that is also bounded simultaneously for estimation filters.
-
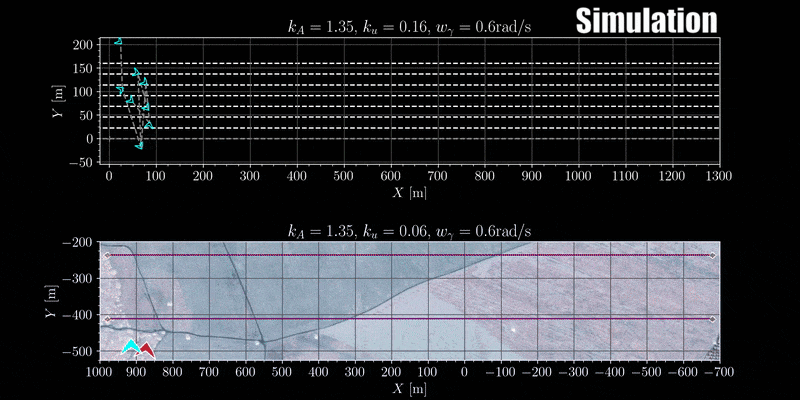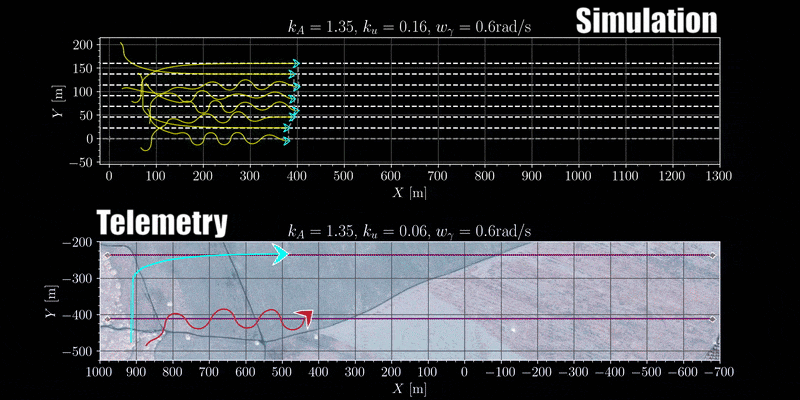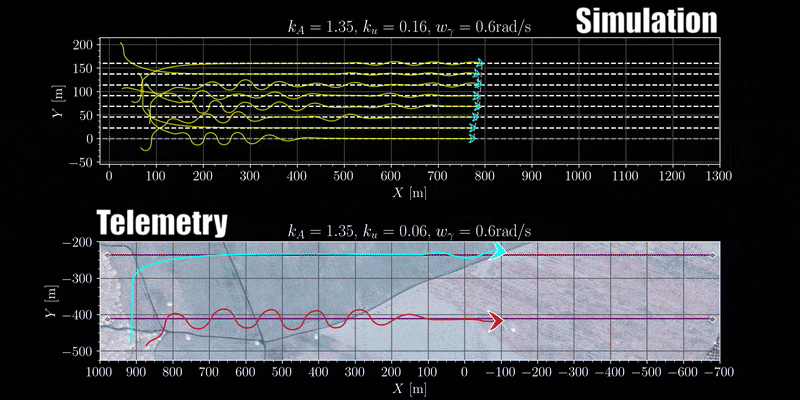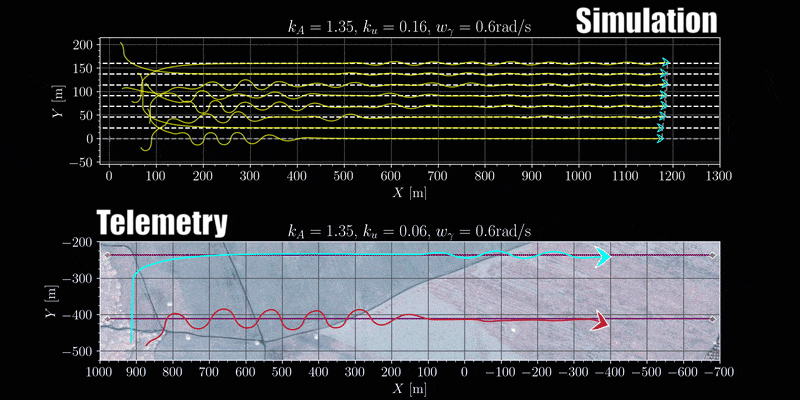
We are back from Hangzhou IROS 2025!
We were presenting our work Distributed Oscillatory Guidance for Formation Flight of Fixed-Wing Drones.
-
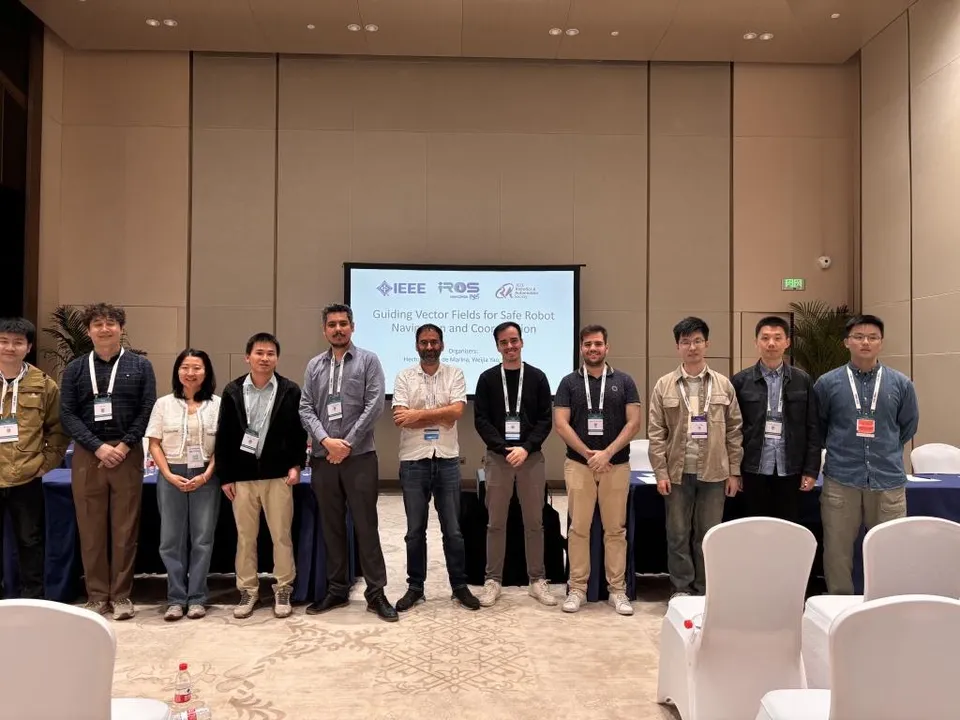
We hosted a workshop exclusively on Guiding Vector Fields during the last day of IROS
It went frankly well considering that it was our first time! Thanks a lot to our speakers and attendees!
-
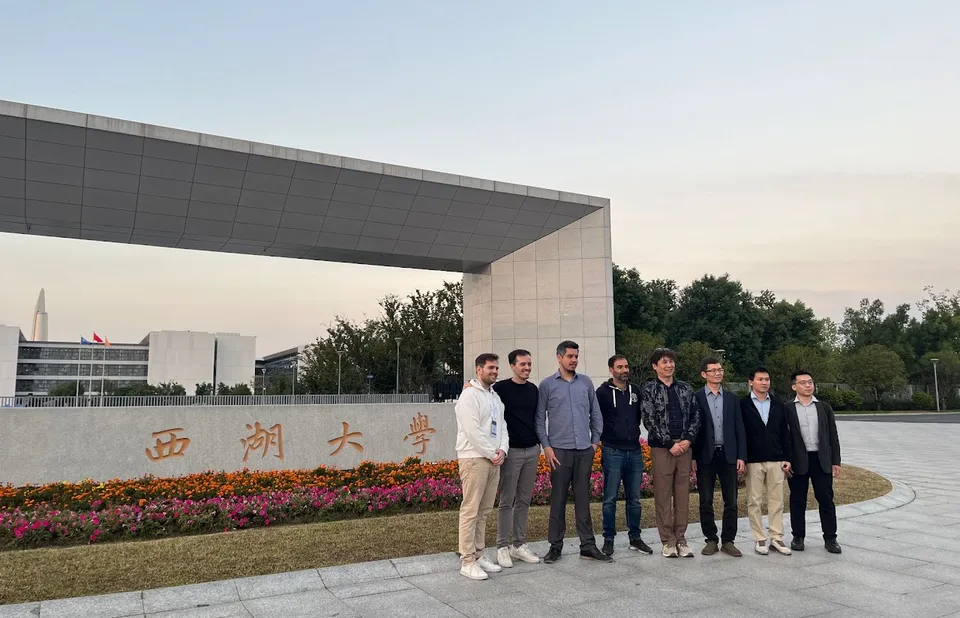
We have visited the Windy lab headed by Shiyu Zhao at Westlake University, Hangzhou
They are doing a great job in aerial manipulation with their recently published Nature paper Proximal cooperative aerial manipulation with vertically stacked drones.
-
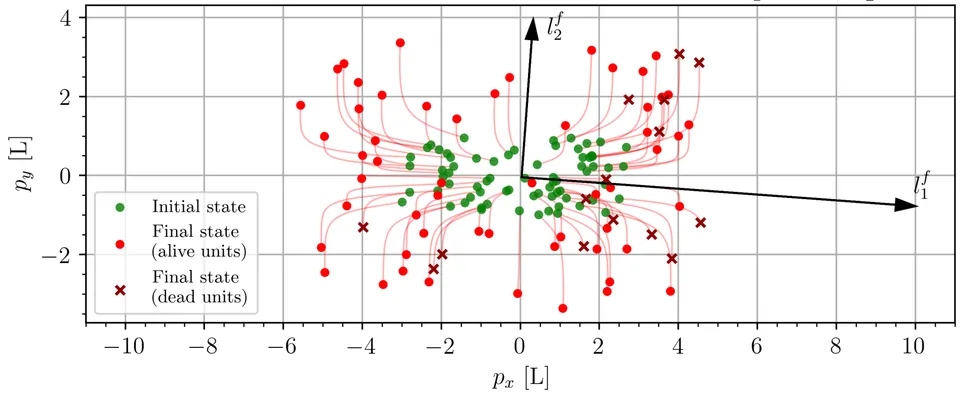
From local to global geometry
Our journal paper titled Dispersion Formation Control: from Geometry to Distribution by Jin Chen, Jesús Bautista, Bayu Jayawardhana, Hector Garcia de Marina, has been accepted for publication in the IEEE Transactions on…
-
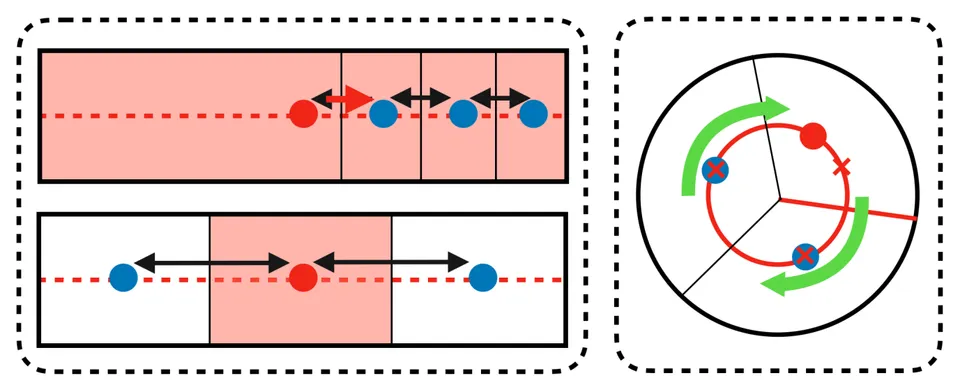
How sensing imperfections impact area coverage algorithms?
Our paper titled Voronoi-Based Area Coverage Algorithms: Turning Real-World Fragility into Strength, by Juan Bosco Román Camacho, Enric Morellà Violeta, Omur Arslan, Hector Garcia de Marina, has been accepted at the…
-
Making progress on the relative localization within robot swarms
Our paper titled Multi-Robot Relative Localization Using Interior Angle Measurements authored by Liangming Chen, Hector Garcia de Marina, Lihua Xie, and Chi Zhang, has been accepted for publication in the IEEE…
-
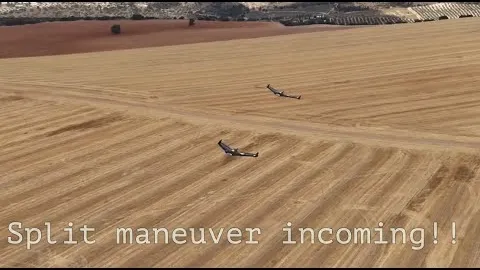
In this demonstration, we show how two fixed-wing drones can rendezvous, fly in formation, split, and meet again at a different location - all while flying at 18 m/s
The key is not about controlling the speed; the drones adjust their trajectories cooperatively to ensure successful rendezvous - all guidance runs entirely onboard. With this strategy, wind is no longer a major obstacle.
-
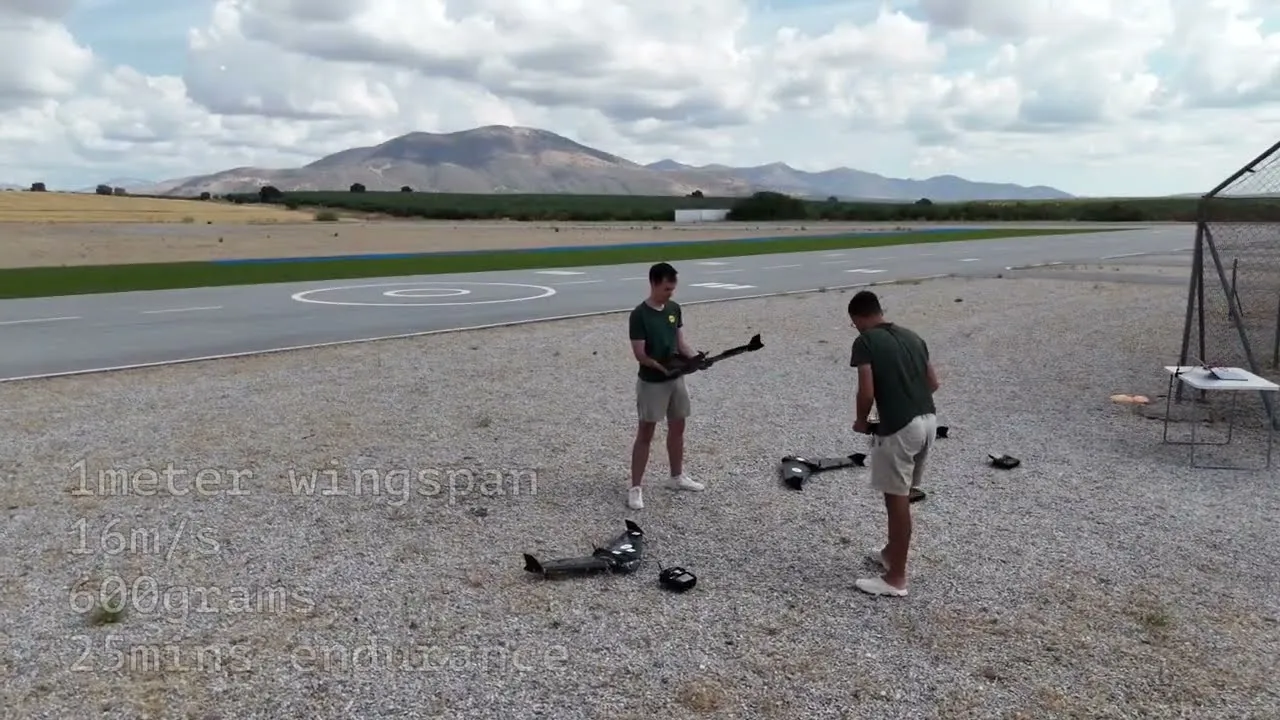
We want to show you a 3D square formation with four flying wings
As always, all the logic is on board and distributed. With sound it is always better.
-
We are collecting a lot of raw videos from our experiments, so we decided to start our own Youtube channel:D
We are collecting a lot of raw videos from our experiments, so we decided to start our own Youtube channel :D. Our first video shows how our onboard guiding system compensates for strong wind scenarios, and coordinates…
-
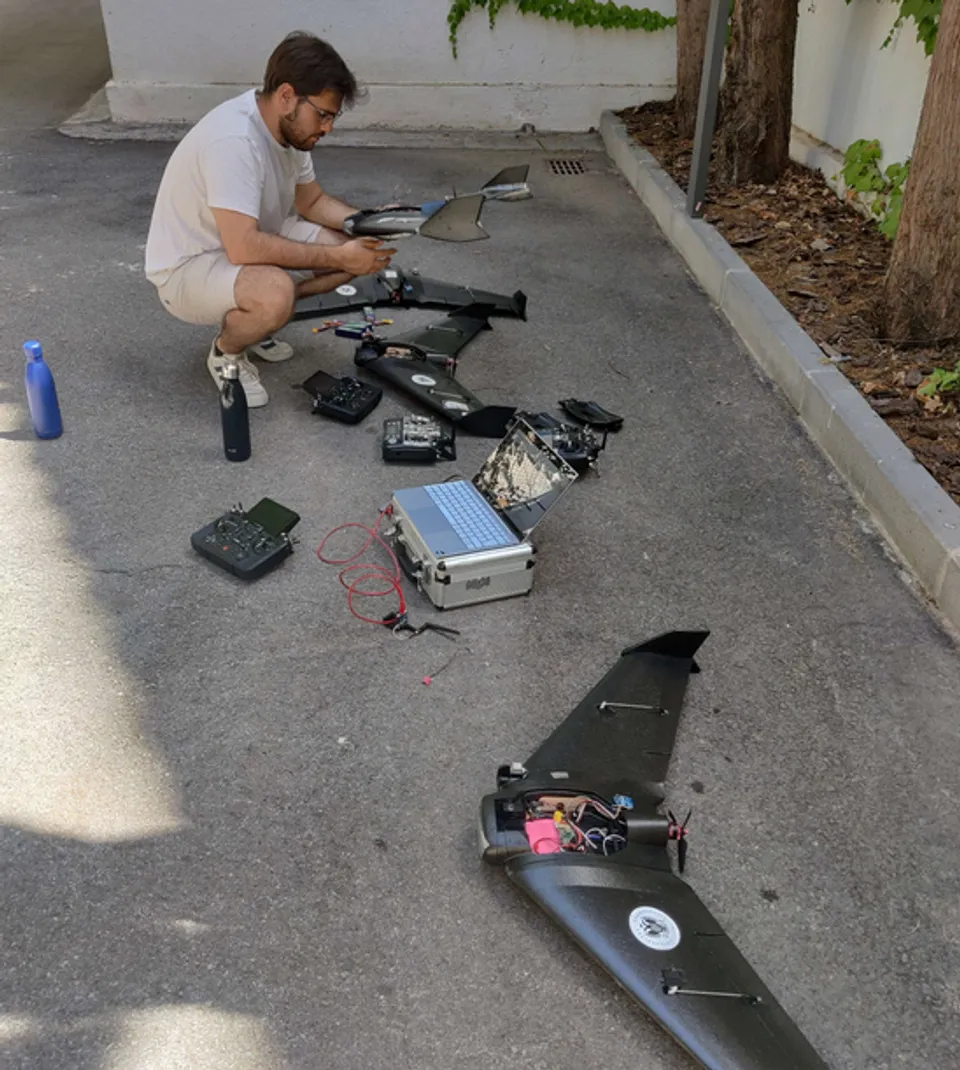
We are getting ready to fly four aircraft in a tight, coordinated formation as we begin scaling up our operations with our fleet of fixed-wing drones, marking an important step toward larger and more complex deployment capabilities
Logistics matter when your swarm grows, and it can be an important bottleneck.
-
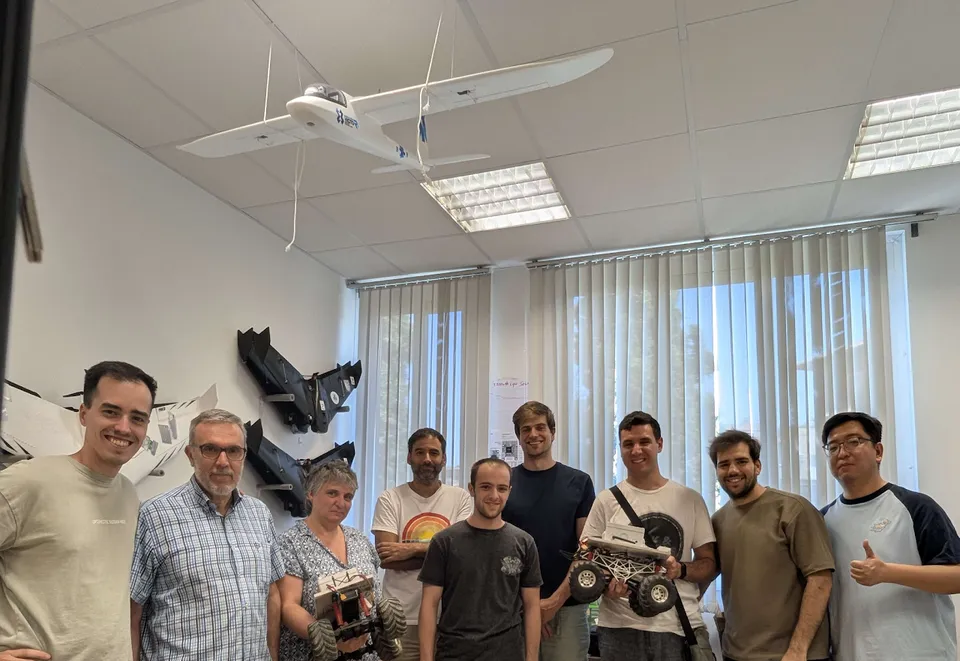
The Robotics and Automation Group from the Faculty of Physics at the Complutense University of Madrid has been visiting us over the past few days
We’re working together on a joint proposal and exchanging ideas on autonomous guidance. They’re always more than welcome in Granada! 😄 Looking forward to seeing them again very soon.
-
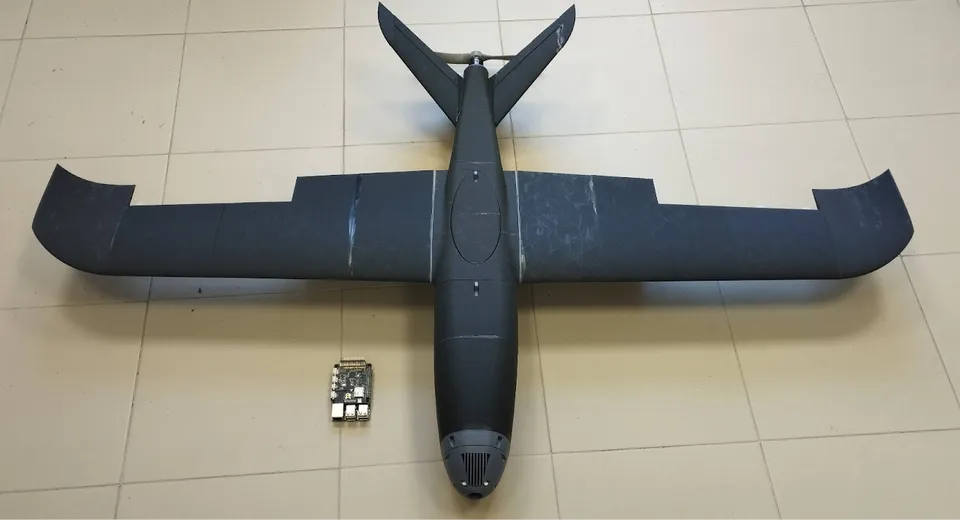
We started building our next generation of fixed-wing drones, fully 3D printed
Now, we can print and build one fixed-wing in about one week for a price less than 150 euros (excluding the autopilot and battery). Maiden flight scheduled by the end of July!
-
Today the Secretary of Research and Innovation of Andalucia visited our new facilities at the Institute of Mathematics of the University of Granada (IMAG)
We effectively moved our activity to IMAG where we have found a great match with their groups on differential geometry and analysis of differential equations! Thanks for the great welcome! News in Spanish
-
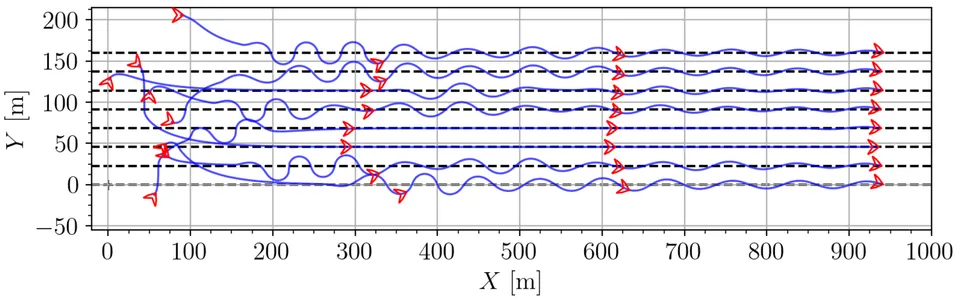
Our paper titled Distributed Oscillatory Guidance for Formation Flight of Fixed-Wing Drones has been accepted for publication in IROS 2025!
The competition has been very tough with only the 46% of the submissions being accepted. Our paper introduces a novel way on how to coordinate vehicles on arbitrary paths.
-
Michele Cucuzzella, Associate Professor at the University of Groningen, the Netherlands, visited our group and gave a very inspiring talk titled Krasovskii passivity based consensus algorithms
Thanks a lot for the visit and all the exchange of ideas on consensus algorithms! We hope you enjoyed visiting Alhambra as well:P.
-
Back from Atlanta!
We have presented two works Inverse Kinematics on Guiding Vector Fields for Robot Path Following and Distributed Versatile Maneuvering with Generalized Formations Using Guiding Vector Fields.
-
We are pleased to invite you to our upcoming Workshop on Guiding Vector Fields (GVFs) for Autonomous Robots, taking place at IROS 2025 in Hangzhou, China
Guiding Vector Fields (GVFs) have emerged as a powerful and versatile framework for autonomous robot navigation, enabling effective motion control in a variety of settings.
-
Professor Christos Verginis from Uppsala University in Sweden has been visiting us this week
His work focuses on multirobot systems and control theory. It was a great time for many discussions and future collaborations.
-
-
-
We are pleased to announce that two papers co-authored with our collaborators on guiding vector fields for drone systems have been accepted for presentation at ICRA 2025
"Inverse Kinematics on Guiding Vector Fields for Robot Path Following" by Yu Zhou, Jesús Bautista Villar, Weijia Yao, Gang Zheng, Andrey Polyakov, and Hector Garcia de Marina.
-
Jesús presented our paper at CDC in Milan titled Resilient source seeking with robot swarms
Full packed room! And a lot of discussions and potential collaborations afterward!
-
Professor Heiko Hamann from the University of Konstanz, who is specialized in robot swarms, is visiting us for two weeks!
He gave an inspiring talk on swarm robotics; it was very interesting to know about how adding more robots to the network can decrease the performance of the team, and how hysteresis plays a role in order to remove…
-
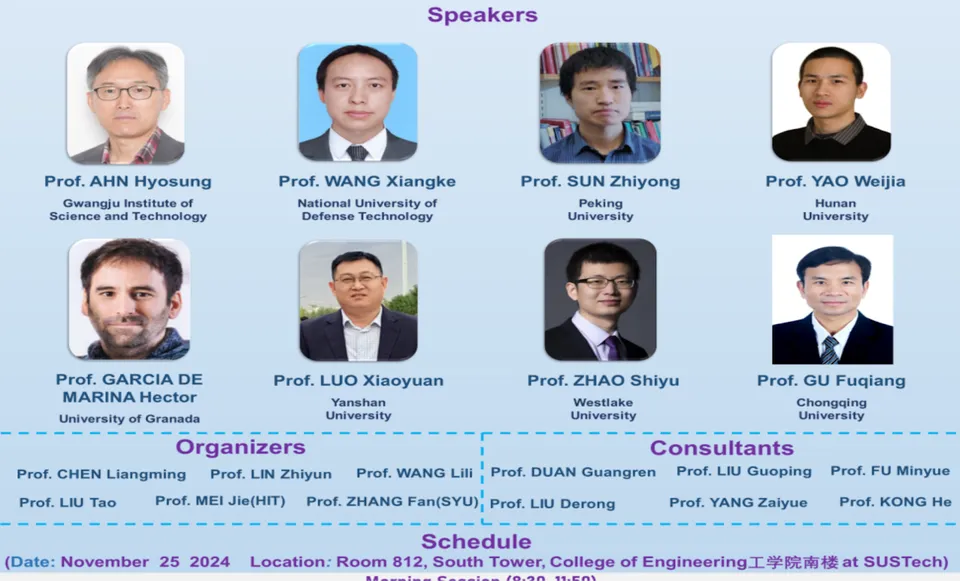
Héctor participated in the Symposium on Localization and Cooperative Control of Intelligent Systems at the Southern University of Science and Technology in Shenzhen, China
We were revisiting how rigidity and other strategies in formation control can assist with current open problems in robotics. It was great to meet with old friends again!
-
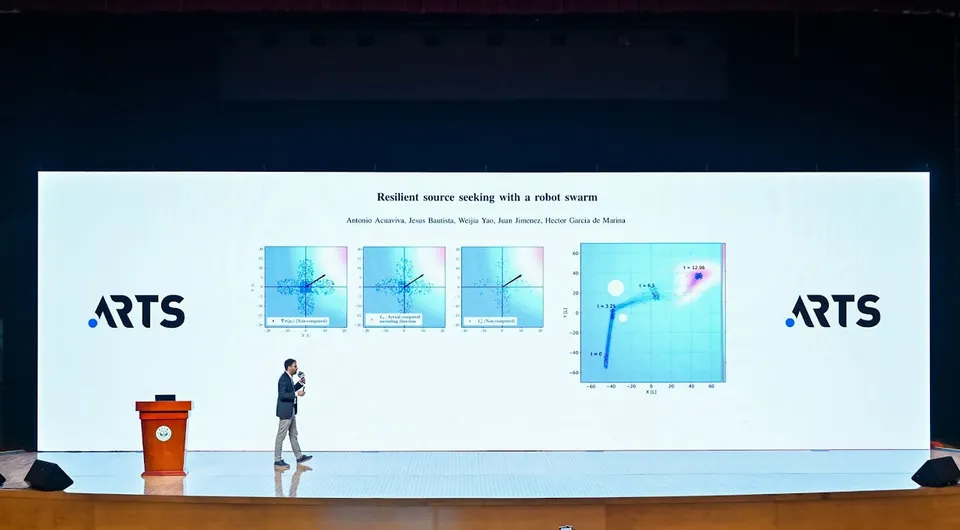
Héctor was invited to give a plenary talk at the second edition of ARTS (Autonomous Robotic Technology Seminar) in Shenzhen, China
This is a forum where young researchers in robotics gather to exchange experiences and update our community (around 1000 attendees!) with our latest results.
-
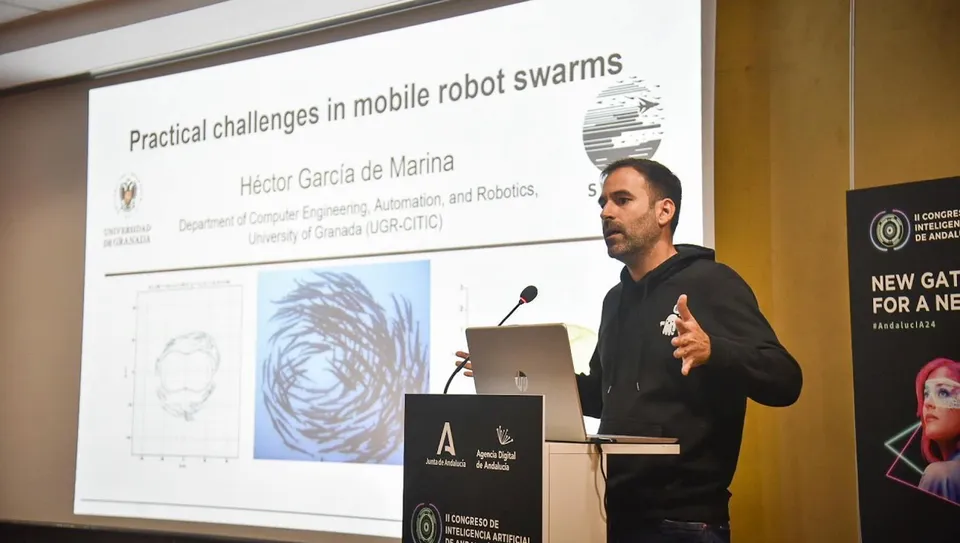
Héctor gave a talk at the II Andalucía AI Congress on Practical Challenges in Robot Swarms
The audience was highly diverse, including people from academia, industry, the military, and ordinary citizens who were eager to learn what a robot swarm truly is. We even made to the news!
-
Eduardo Montijano and David Morilla from the University of Zaragoza were visiting our lab
We were discussing how to integrate active perception to our drones, and how to enhance our distributed algorithms with dynamics consensus algorithms.
-
We have a visitor!
Yu Zhuo from INRIA, Lille, France. He is a Ph.D. student under the supervision of Andrey Polyakov and Gang Zheng, and his research is on Guiding Vector Fields for autonomous vehicles.
-
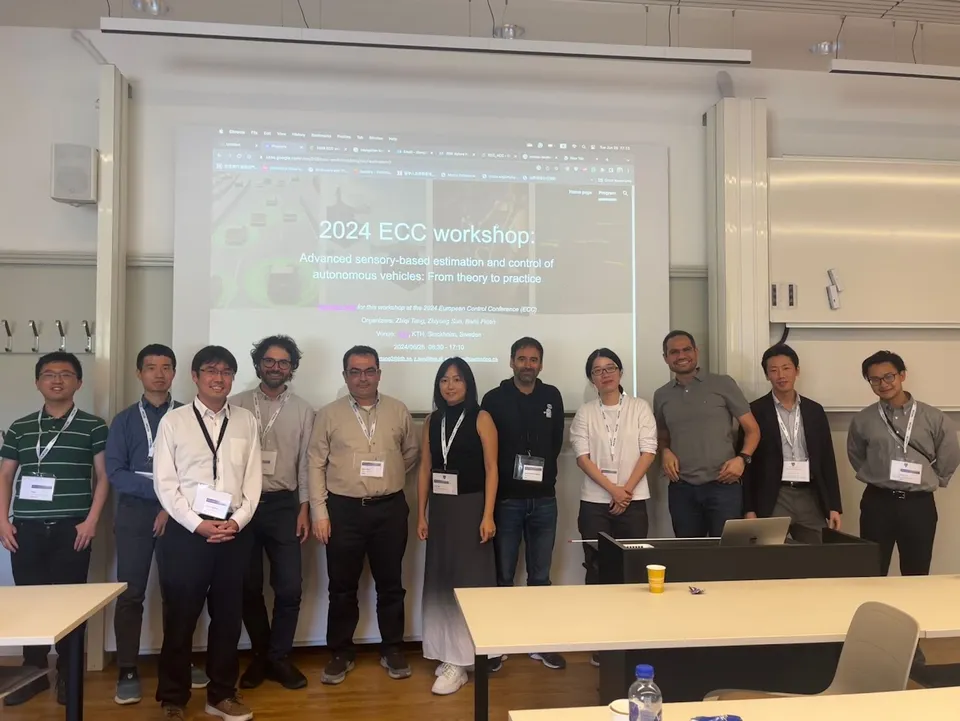
Héctor was presenting our work on source seeking for robot swarms in two workshops at the European Control Conference in Stockholm
Workshop on Advanced sensory-based estimation and control of autonomous vehicles. Workshop on Task and Motion Coordination under Geometric, Dynamic and Temporal Constraints.
-
Our work on how to coordinate unicycles without orientation measurements has been accepted for publication!
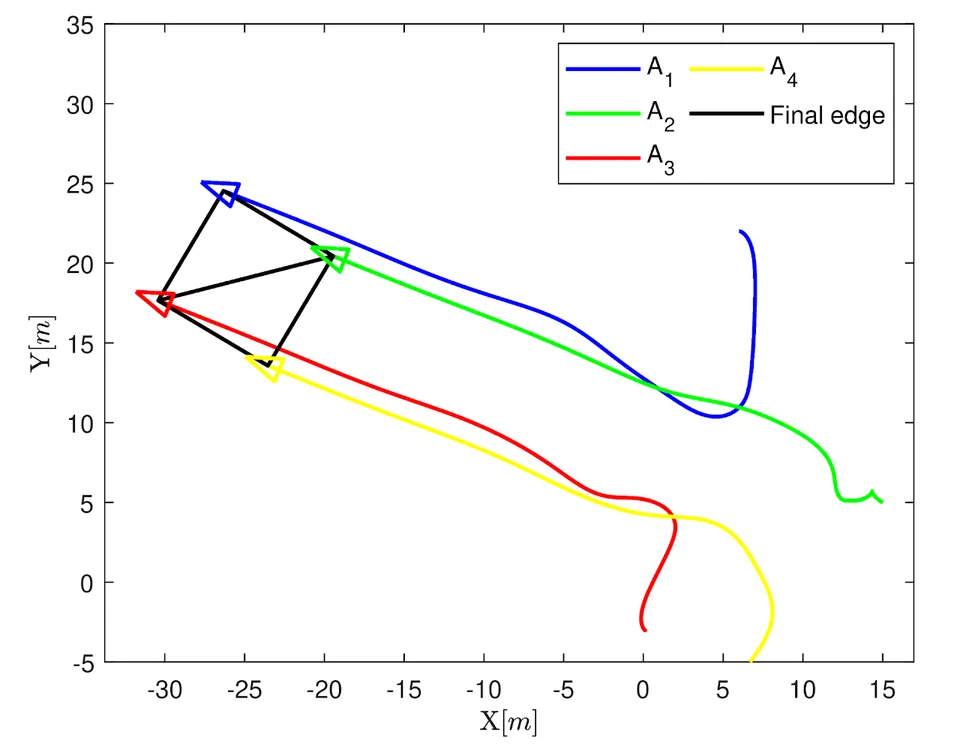
We prove rigorously intuitive results; as we can see in the figure, the vehicles' alignments are under control if you control distance-rigid formations of moving unicycles using only relative positions. J. Chen, B.
-
Our work Resilient source seeking with robot swarms by A
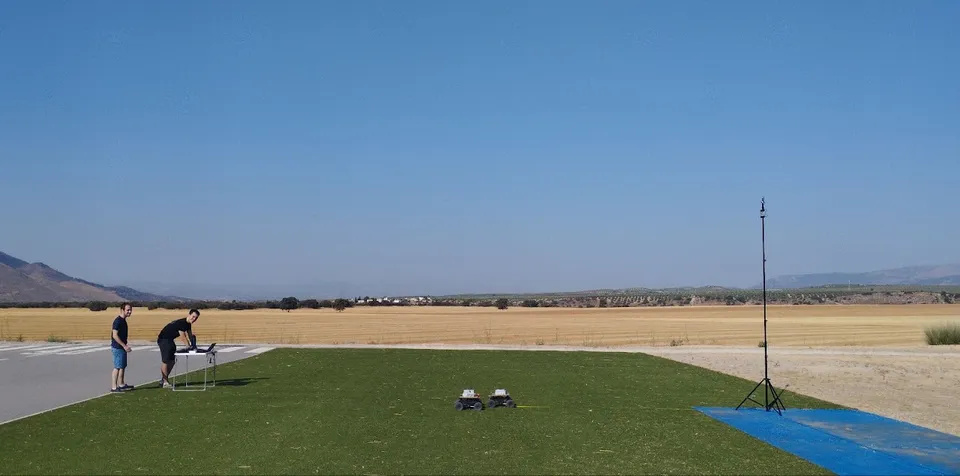
Acuaviva, J. Bautista, W. Yao, J. Jiménez, HG de Marina has been accepted in the 63rd IEEE Conference on Decision and Control (CDC) 2024! The next step is the journal version with real robots!
-
Jesús and Héctor have written a tutorial for aligning 3D unicycles with partially known vector fields using geometric controllers
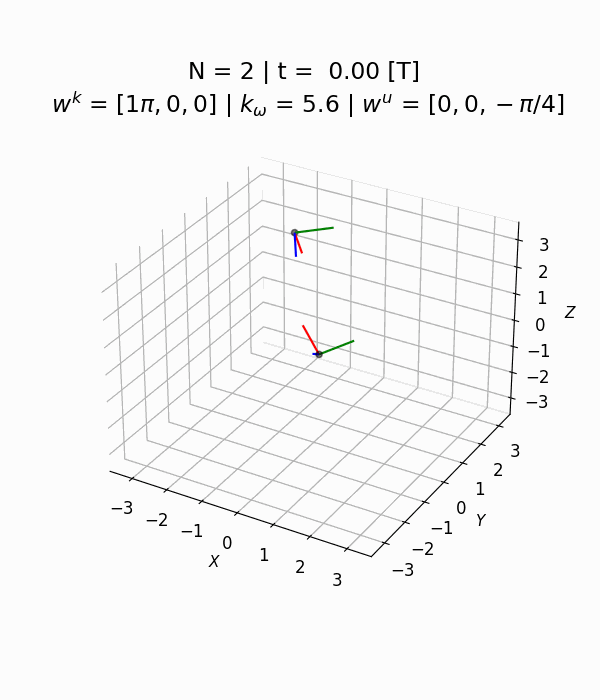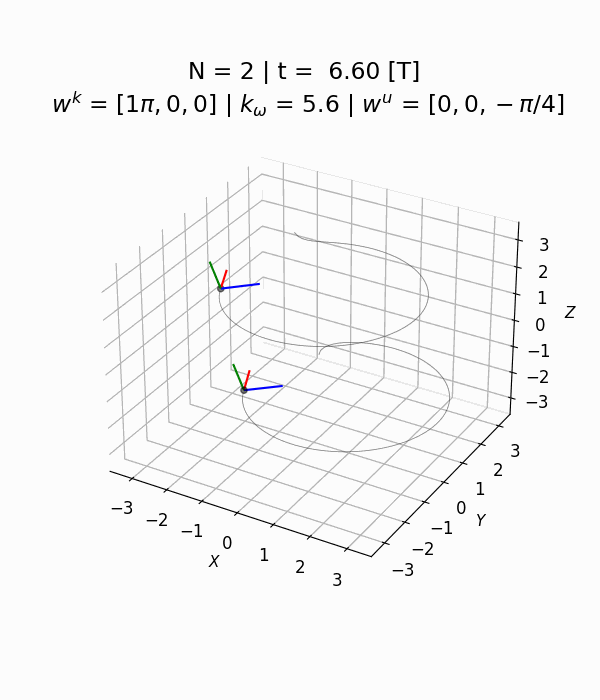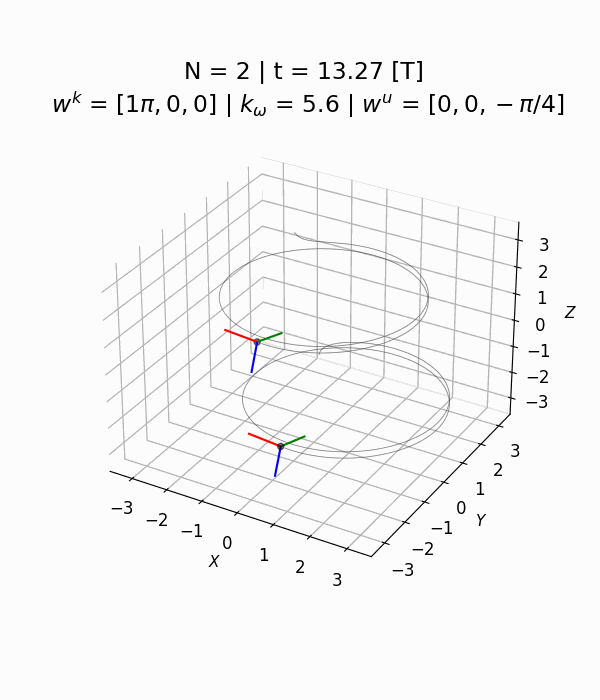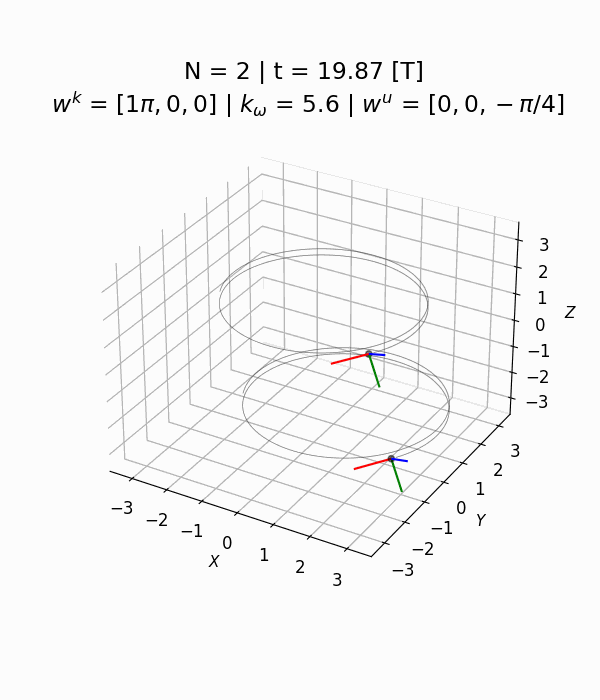
We have digested concepts that are not so common in robotics with very explicit examples. This technical note aims to introduce geometric controllers to roboticists bridging some gaps between theory and practice.
-
Journal paper accepted!
Our work titled Scaling up the formation of agents with heterogeneous sensing: mixed distance and bearing-only by J. Chen, B. Jayawardhana and HG de Marina will be published in IEEE Transactions on Automatic Control.
-
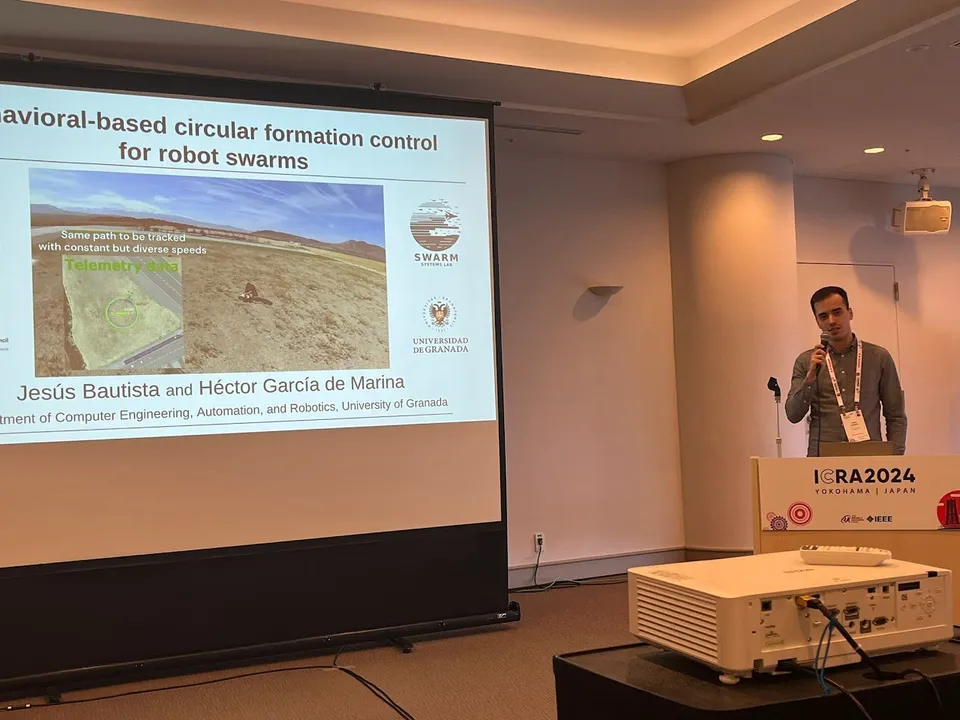
We are back from ICRA 2024 in Yokohama!
Jesús presented our work titled Behavioral-based circular formation control for robot swarms.
-
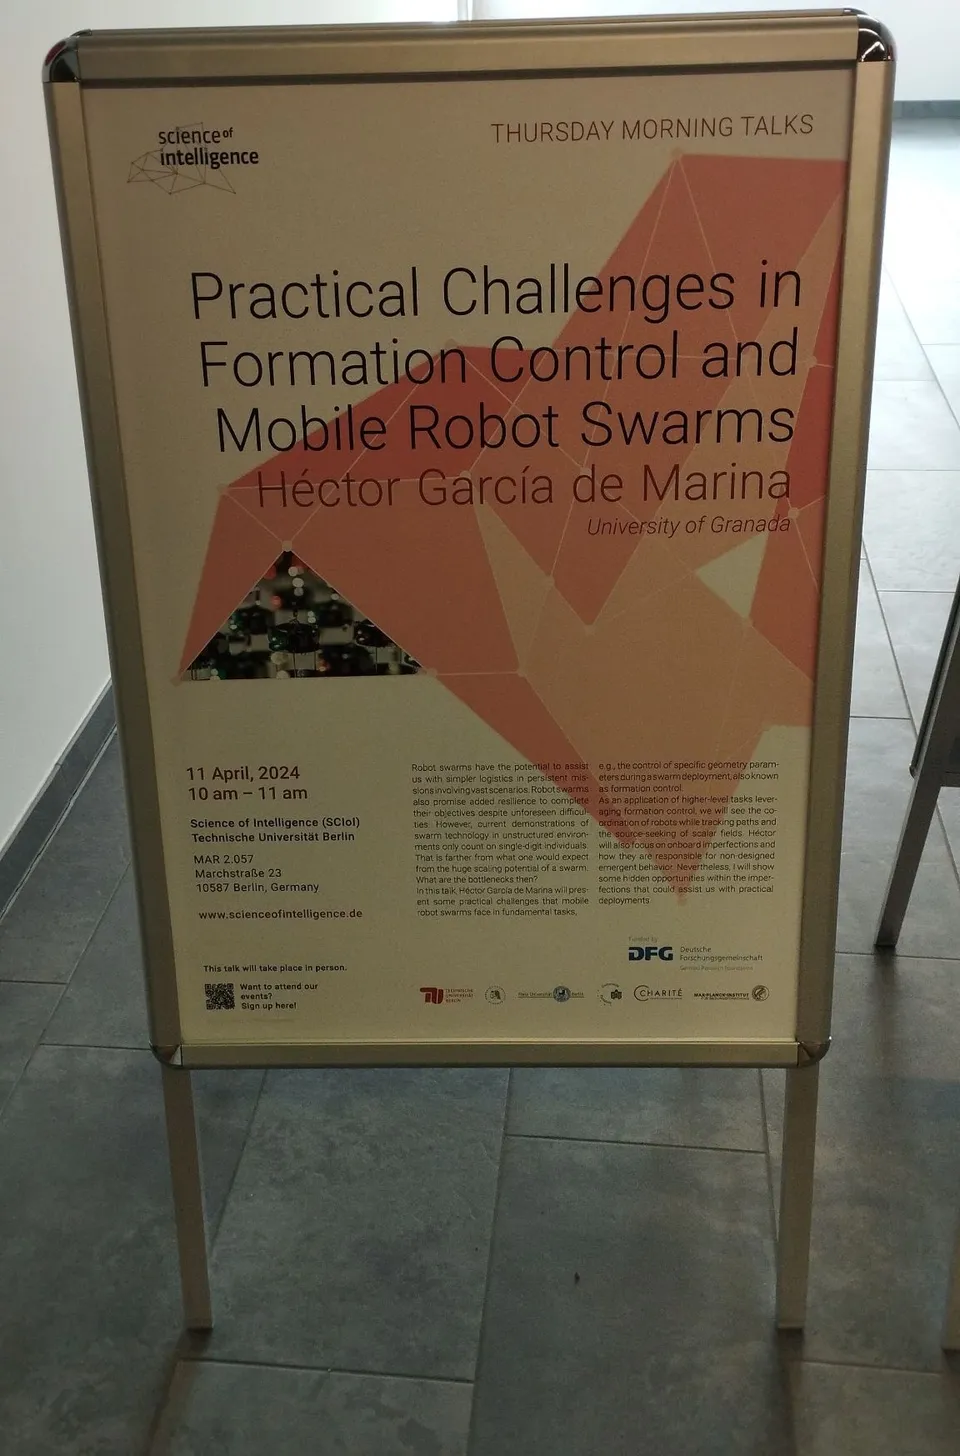
Héctor was visiting the Science of Intelligence Institute in Berlin mainly joined by researchers from Technische Universität Berlin and the Humboldt-Universität zu Berlin
Héctor gave a talk about the practical challenges that swarm robotics are facing from the perspective of control engineering.
-
Héctor was visiting the University of Zaragoza and its Robotics, Perception and Real Time Group
He met many robotics colleagues and exchanged many interesting ideas! He also gave a talk about swarm robotics (we could not tell). It was really productive, and some interesting collaborations emerged regarding our ERC…
-
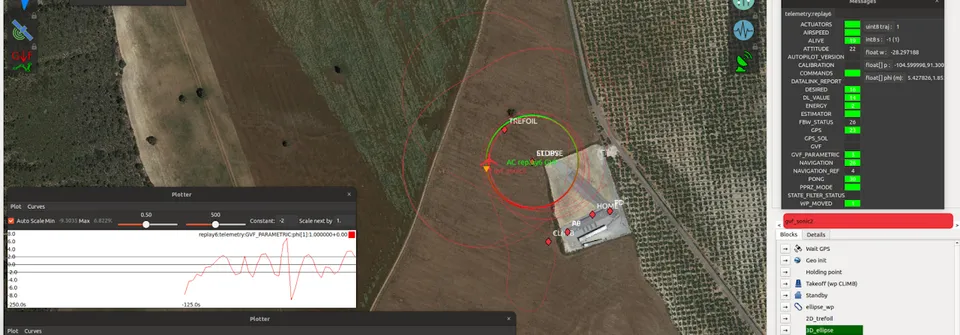
Today, we tested new adjustments in the altitude controller of our aircraft
It is astonishing to check that in a 3D trajectory (ellipse, 60m peak, 40m low) our vertical controller kept the error between +-2meters! (plot above).
-
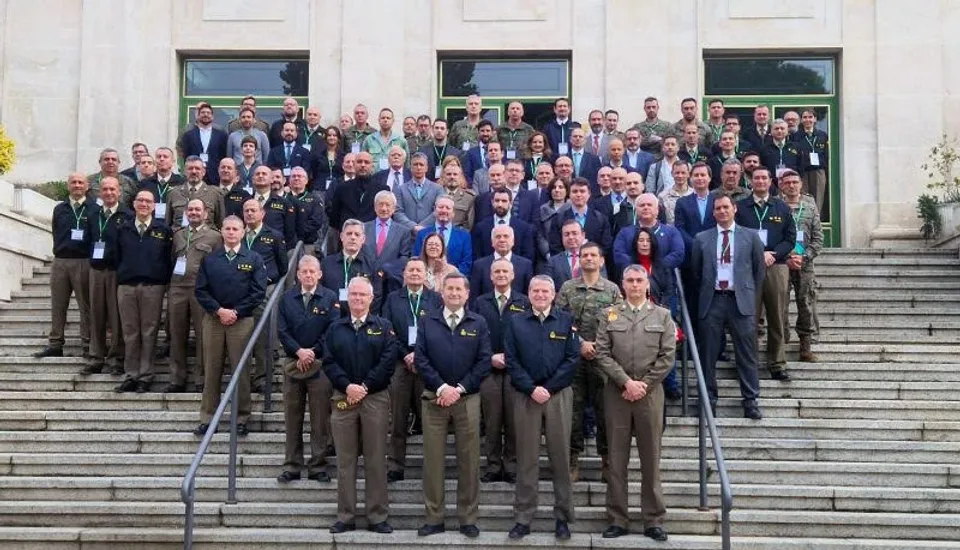
Our lab was invited to introduce what is the (drone) swarm technology and its state-of-the-art to the Spanish Army
The (four stars) general of the Spanish Army attended our presentation!
-
Our friends from CanalSur (Spanish TV from Andalucia) made a reportage about our research on swarm robotics!
In this video, we explain the concept of a robot swarm and what are the applications of swarms of drones in the real world. 13 /10/202 3 Jin, a Ph.D. student from the University of Groningen, is visiting us this October.
-
( OPEN POSITIONS!) We have opened a Ph.D
position within our ERC project Controlling imperfect robot swarms. We are also interested in hosting FPU candidates at our lab. If you are interested or you know somebody who is a good match; please, check out the…
-
oMg!
The ERC contacted Héctor this morning. His proposal titled Controlling i mperfect robot swarms got awarded with the Starting Grant! Huge!
-
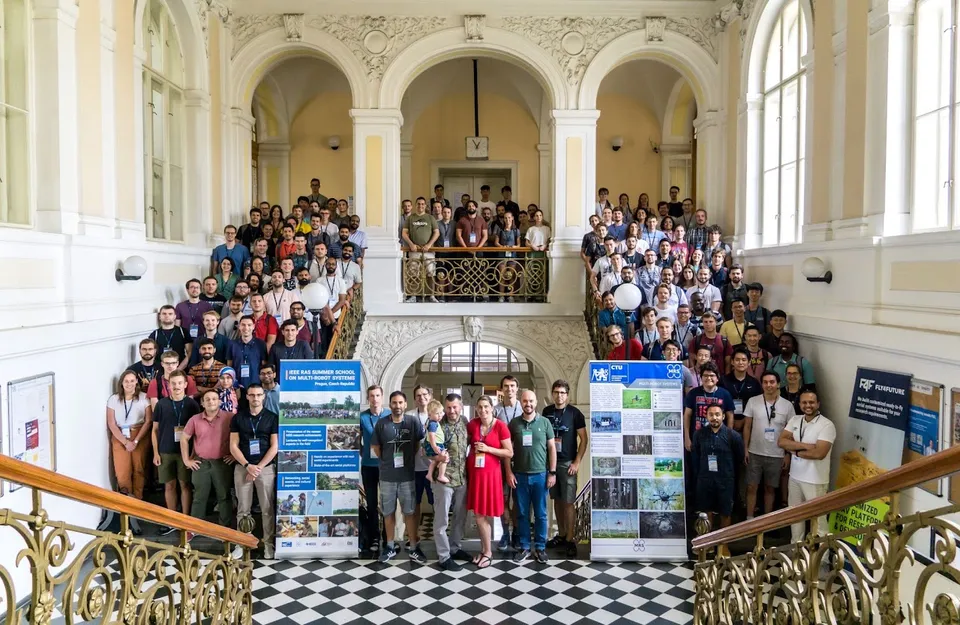
The 2023 IEEE RAS Summer School on Multi-Robot Systems was a huge success!
Students were engaged, invited lecturers had an outstanding level, and the city of Prague is certainly beautiful. Thanks again for such a nice invitation!
-
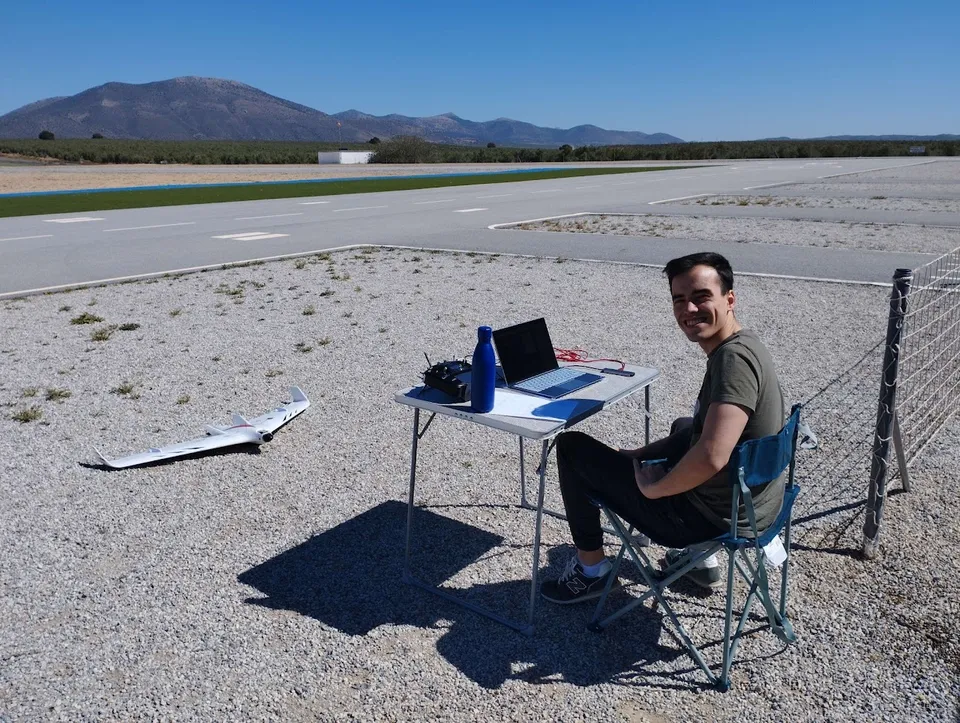
First maiden flight for Jesús!
There is always a first time, and he was an excellent ground-mission controller! We flew an Opterra 1.2m successfully and collected the necessary flight data for its trimming in the lab later on.
-
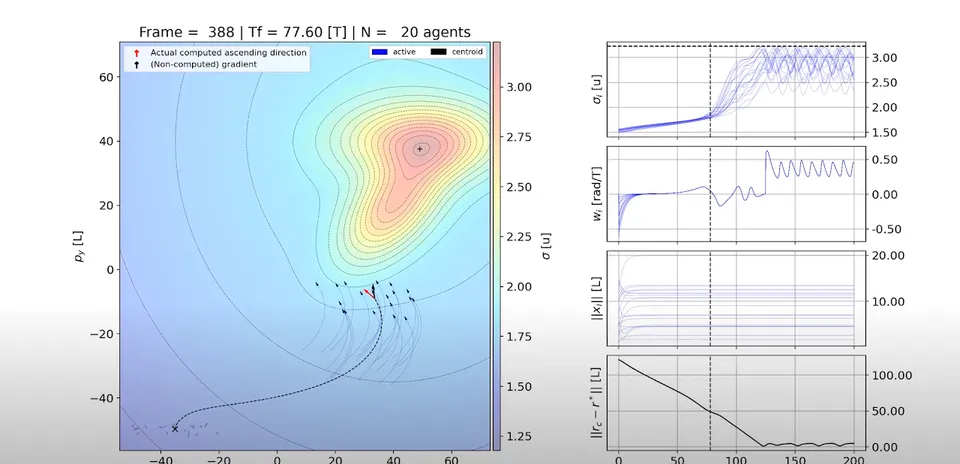
Héctor was invited to give a lecture at the 2023 IEEE RAS Summer School on Multi-Robot Systems together with other researchers like Dario Floreano and Javier Alonso-Mora, organized by the Czech Technical University (CTU) in Prague
He will present his latest results on source-seeking with resilient robot swarms. Hope to see you there!
-
Congratulations Jin!
We had an accepted paper in the American Control Conference on..... of course, formation control:P. The title of the article is Distance-based Formation-Motion Control for Unicycle Agents written by Jin Chen (Ph.D.
-
Héctor gave a talk on swarm robotics and formation control at the Beijing University of Technology
Hopefully, next time it will be in person:P.
-
The ERC just informed Héctor that they propose his Starting Grant for funding (maximum score, A, yei!)
However, he is in the reserve list:S. Who knows whether the list will catch him after the UK not being part of the program this year either.
-
Changing the mood, Héctor would like to introduce you to our fantastic facilities for our flights at RC Club ciudad de la Alhambra
Astonishing landscape with mountains, lots of space to fly, and clear runaways. He feels very fortunate to be part of this club!
-
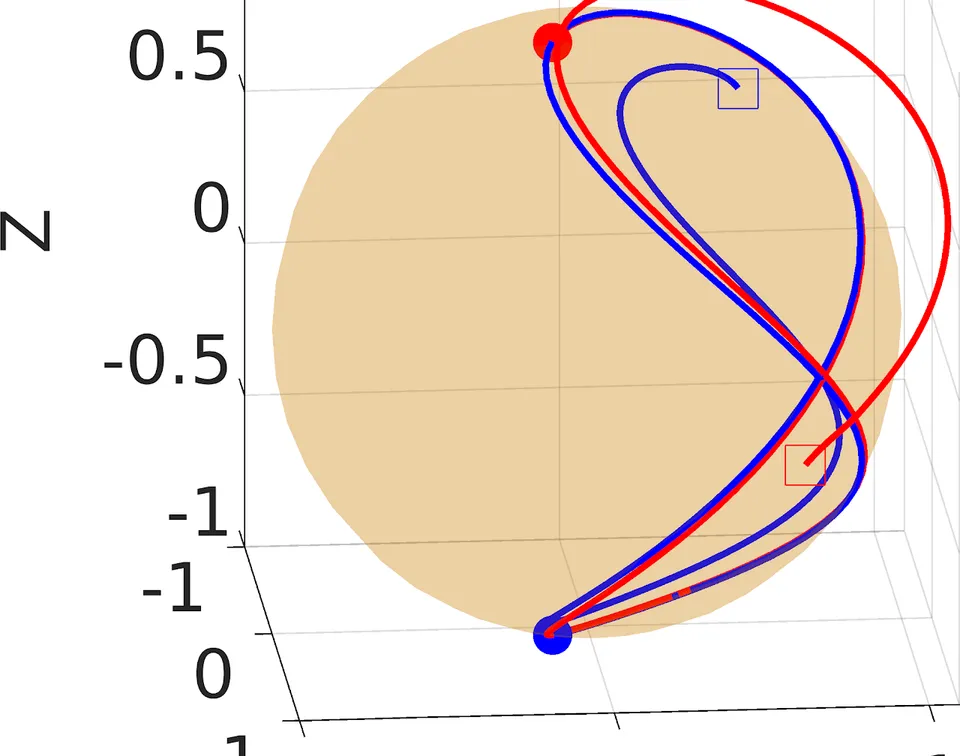
The matured work from our paper nominated for the best paper award in ICRA has been accepted in IEEE Transactions on Robotics!
In this work, we show how to coordinate distributely teams of robots on 3D surfaces with strong converge guarantees. As usually, we provide real experiments with aircraft, and the implementation is ready for the general…
-
We were working with Haiwen Wu (Ph.D
student in Groningen) on the application of formation control techniques to arm manipulators. He conducted a very detailed analysis on to apply different distance and position-based control to arm manipulators with…
-
Congratulations Adam!
Our (former) Ph.D. student made it to IROS 2022. Our paper titled Energy-Aware Planning-Scheduling for Autonomous Aerial Robots exploits typical periodic patterns in survey missions to optimize the energy consumption of…
-
Héctor was invited to give a talk by the control engineering group at Cambridge University
This talk belongs to a series of seminars devoted to control theory topics. It will be held on the 30th of June, it is online, and if you are interested you can find more information here.
-
It is official now
From the 1st of April, Héctor will start as a Ramon y Cajal researcher at the University of Granada, in the beautiful city of Granada.
-
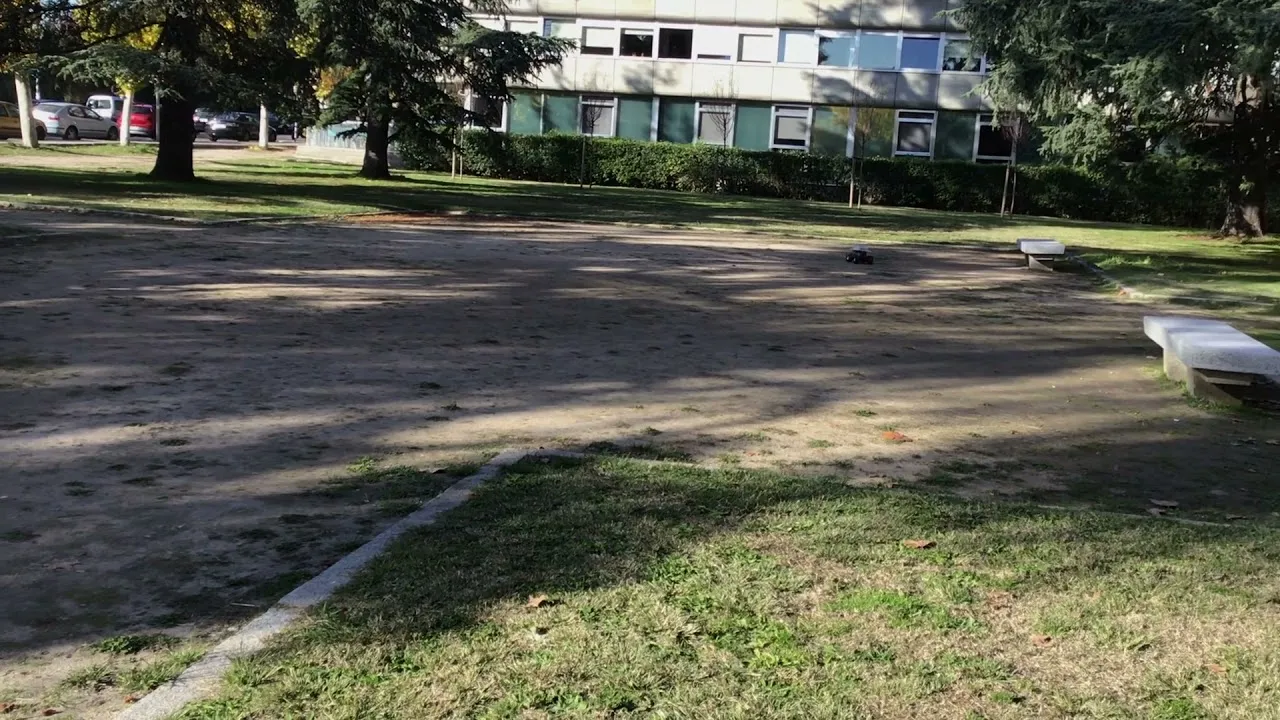
Our new team member Jesús has ported Paparazzi, the opensource autopilot, to off-road rovers!
A new firmware has been programmed, and it has been made compatible with the guidance from the Guiding Vector Fields that has worked wonderfully for our planes.
-
Héctor has been awarded the Ramón y Cajal grant!
That is (arguably) the most prestigious Spanish grant for young investigators, and it guarantees five years of independent research funded by the Spanish government.
-
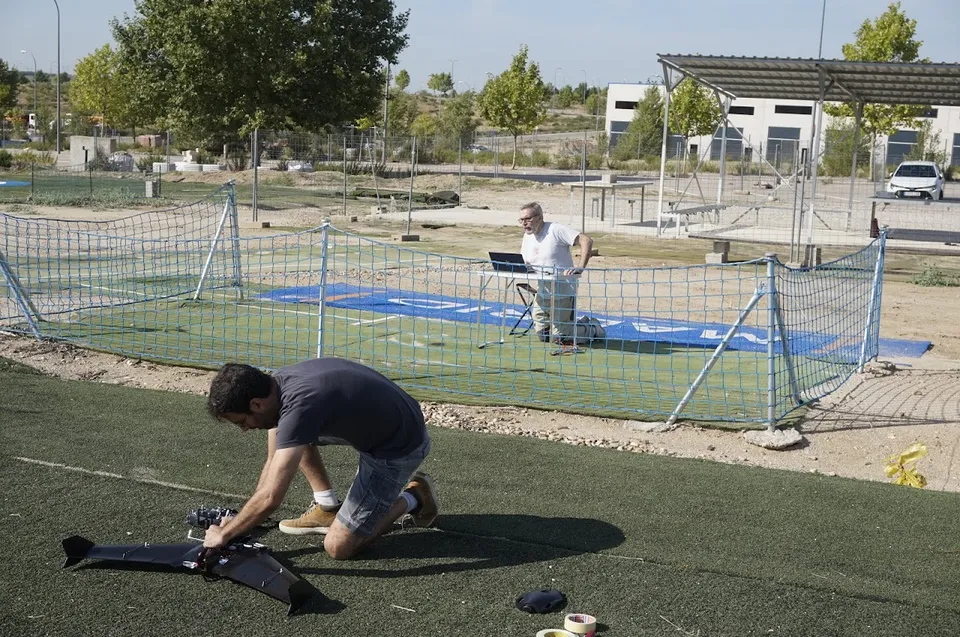
The first copy for Héctor's aerial swarm had a successful maiden flight!
In fact, this is his first autonomous flight at his new club in Arroyomolinos. Nice to be licensed to fly aeromodels again. The aircraft is a Sonicmodell AR.Wing 900 geared with Paparazzi, the open-source autopilot.
-
Héctor was appointed as Associate Editor of the IEEE Transactions on Robotics
He is very excited to serve for the flagship journal of the IEEE Robotics & Automation Society, one the top robotics publications in the world.
-
Our works in formation control has been positively welcomed in the 60th IEEE Conference on Decision and Control ( CDC ) 2020!
The first work, with Haiwen as first author, we explore formation control algorithms applied to arm manipulators Distributed formation control of manipulators' end-effector with internal model-based disturbance…
-
We were contacted by the ICRA's organization today
Our submission Distributed coordinated path following using guiding vector fields has been nominated for the BEST PAPER AWARD together with other three finalists!
-
Our only submission to ICRA has been accepted!
Our work titled Distributed coordinated path following using guiding vector fields shows how to guarantee formally the global convergence of a team of agents to a desired path in arbitrary dimensions and with a desired…
-
Héctor and his colleague Leonardo Colombo have received good news about our paper titled Forced Variational Integrators for the Formation Control of Multi-Agent Systems
It has been accepted in IEEE Transactions on Control of Network Systems! In this work, we explore the applications of Variational Integrators for large simulations in multi-agent systems.
-
Today, we have been informed that our paper titled Singularity-free Guiding Vector Field for Robot Navigation has been accepted in IEEE Transactions on Robotics in the first round of reviews!
In this work, we (with Weijia Yao from Groningen as main author) show how to construct guiding fields for robots with complex dynamics to track non-trivial paths, e.g., self-intersected 3D ones.
-
Our paper titled Maneuvering formations of mobile agents using designed mismatched angles has been accepted in IEEE Transactions on Automatic Control
In this work, Liangming Chen from the University of Groningen explores and analyzes how formations can be maneuvered by adding mismatches to the interior angles to be controlled.
-
This one is special for Héctor since his first contact with control and aeronautics was in the high school when he read for the first time an issue of the Journal of Guidance, Control, and Dynamics
Héctor is very happy to announce that our work titled Collaborative target-tracking control using multiple autonomous fixed-wing UAVs with constant speeds has been accepted in the mentioned journal!
-
Héctor's first solo-authored paper titled Maneuvering and robustness issues in undirected displacement-consensus-based formation control has been accepted in IEEE Transactions on Automatic Control
In this article, he studies the impact of non-perfect sensing on the distributed formation control of agents.
-
We have two accepted works in CDC 2020!
One is our already accepted article Angle-Constrained Formation Control for Circular Mobile Robots, and the second one is a joint work with the guys in Groningen, Mobile Robot Path Following Control in 2D Using a 3D…
-
Our article titled Angle-Constrained Formation Control for Circular Mobile Robots has been accepted in IEEE Control Systems Letters
Nelson made a fantastic job formalizing the relation between bearing-based and distance-based formation control.
-
Héctor starts as a research fellow at the Universidad Complutense of Madrid under the program Atracción de Talento cofunded by the goverment of the Autonomous Community of Madrid
He will continue his research in multi-agent systems and robotics in the Deparment of Computer Architecture and Automatic Control at the Faculty of Physics in Madrid.
-
Our paper titled Forced variational integrator for distance-based shape control with flocking behavior of multi-agent systems has been accepted at IFAC World Congress 2020, Berlin!
This was a joint work with the Institute of Mathematical Sciences (ICMAT) in Spain, and the University of Groningen in the Netherlands.
-
Héctor is honored to join the International IMAV Comittee!
IMAV is a competition and conference event on Mini and Micro Aerial Vehicles that was born in Europe in 2009. After several consecutive years held in Europe, IMAV aimed to be spread worldwide starting in Beijing 2016.
-
Ewoud Smeur from Technical University of Münich was visiting us
We completed the first autonomous flight with Paparazzi at the H.C. Andersen airport!
-
Our paper titled On the observability of relative positions in left-invariant multi-agent control systems and its application to formation control has been accepted at CDC 2019, Paris!
This was a joint work with the Institute of Mathematical Sciences (ICMAT) in Spain.