WHAT WE WORK ON.
The projects behind the work: what each one set out to do, who funds it, who is on it, and the papers that came out of it.
- iSwarm ERC Starting Grant 2023 - 2028
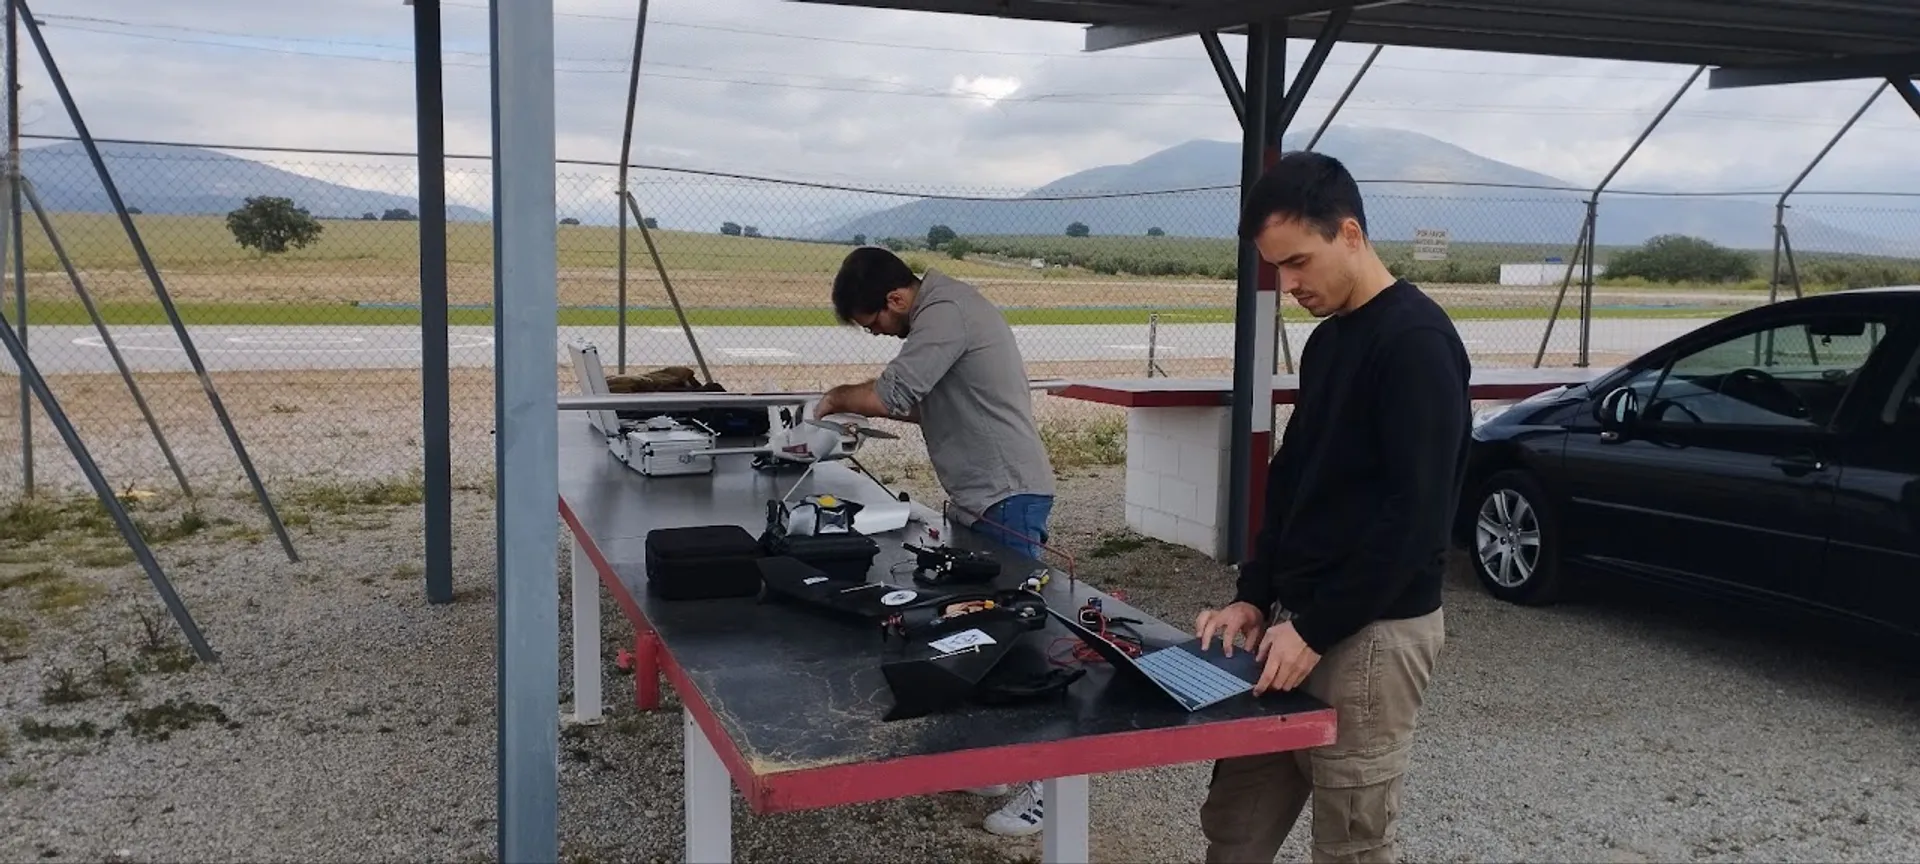
iSwarm: Controlling imperfect robot swarms
A rigorous control theory to unleash and ally with imperfections, such as dropouts, delays, and scaling/biasing factors in sensors and actuators, as novel distributed control inputs for taming emergent behaviors. Our paradigm shift requires new ways of analyzing algorithms and their robot integration at the crossroads between algebraic graph theory, network theory, control, and mechatronics for multi-agent systems.
8 papers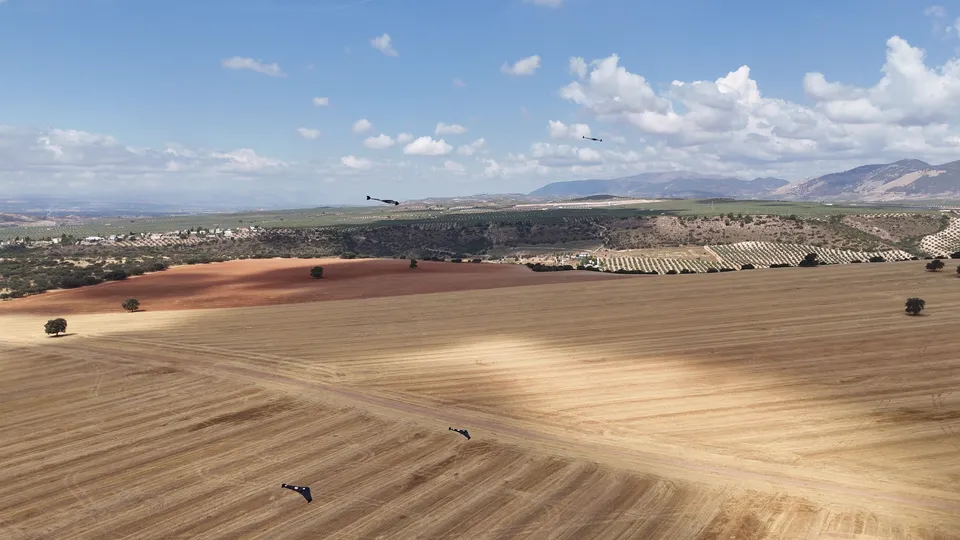
- aerosense ERC Proof of Concept 2026 - 2027
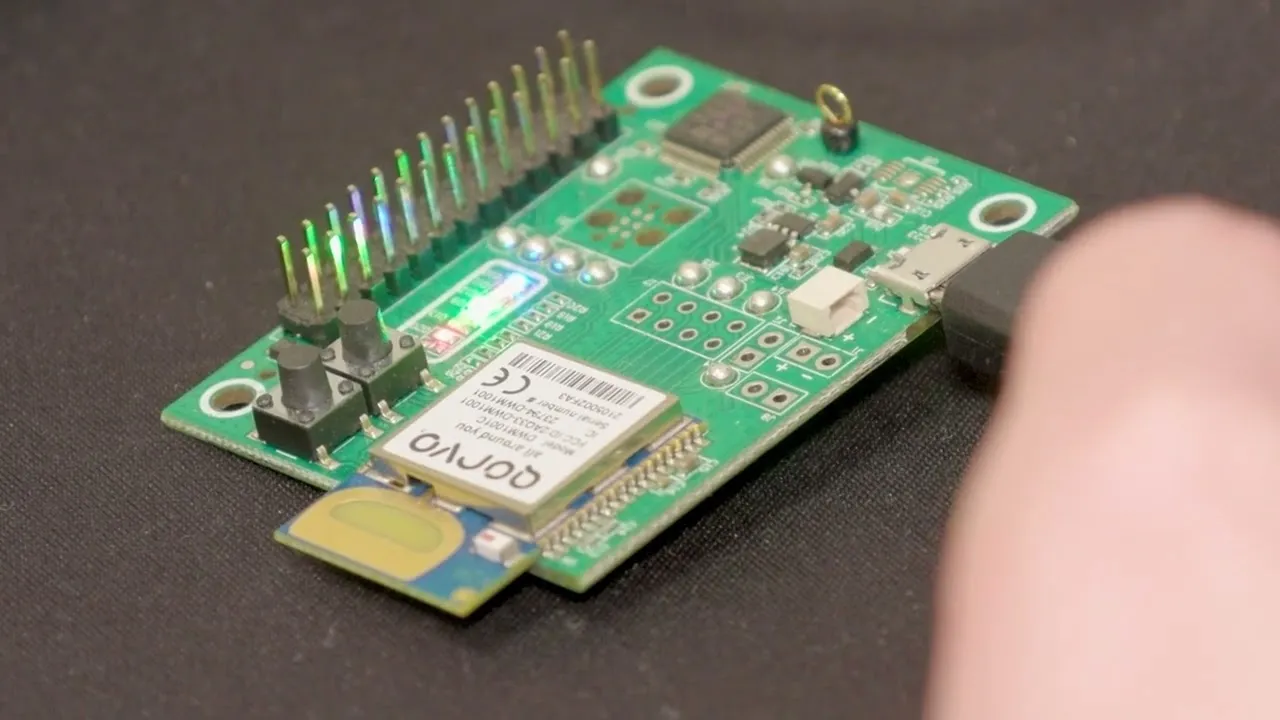
Aerosense: Spatial Awareness Avionics Network for Drone Swarms Aerosense
Aerosense delivers an avionics system purpose-built for distributed spatial awareness and clock synchronization without external infrastructure by integrating Ultra-Wideband (UWB) transceivers with custom protocols operating immediately above the physical layer.