PUBLICATIONS.
Peer-reviewed work in IEEE Transactions on Automatic Control, Transactions on Robotics, Automatica, ICRA, IROS, CDC, and IFAC.
In review
- [U1]
Singularity-Free Guiding Vector Fields on SO(3) with Designer-Specified Progression Behavior
J. Bautista, HG de Marina · Submitted to Automatica
In review Code
2026
- [J28]
Asymmetric Delay-Induced Translation in Displacement Formations
Y. Xu · IEEE Control Systems Letters
Journal DOI - [J27]
Angle-based leaderless formation maneuvering with global convergence
G. Wang, HG de Marina, M. Fu, G. Wen, L. Chen · Automatica
Journal - [J26]
Fully distributed and resilient source seeking for robot swarms
J. Bautista, A. Acuaviva, J. Hinojosa, W. Yao, J. Castellanos, HG de Marina · IEEE Transactions on Automatic Control
- [J25]
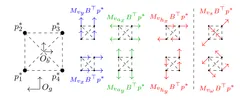
Leaderless Collective Motion in Affine Formation Control over the Complex Plane
J. Bautista, E. Morella, L. Wang, HG de Marina · IEEE Transactions on Network Systems
- [C42]
The distance-based formation controller design for multi-agent systems in port-Hamiltonian form
J. Zhao, Y. Wu, HG de Marina, Y. Wu · IFAC World Congress
- [C41]
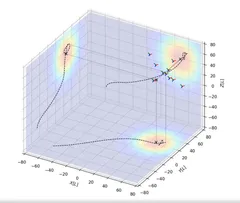
Distributed 3D Source Seeking via SO(3) Geometric Control of Robot Swarms
J. Bautista, and HG de Marina · IFAC World Congress
- [C40]
Linear quadratic control for discrete-time systems with stochastic and bounded noises
X. Ma, S. Zhang, X. Zhang, J. Xin, HG de Marina · IEEE American Control Conference (ACC)
2025
- [J24]
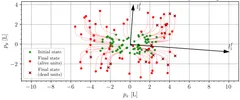
Dispersion Formation Control: from Geometry to Distribution
J. Chen, J. Bautista, B. Jayawardhana, HG de Marina · IEEE Transactions on Automatic Control
- [J23]
Multi-Robot Relative Localization Using Interior Angle Measurements
L. Chen, HG de Marina, L. Xie, C. Zhang · IEEE Transactions on Control Systems Technology
Journal DOI - [C39]
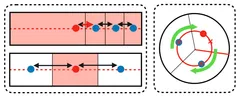
Voronoi-Based Area Coverage Algorithms: Turning Real-World Fragility into Strength
J. Bosco, E. Morellà, O. Arslan, HG de Marina · IEEE International Symposium on Multi-Robot and Multi-Agent Systems (MRS)
- [C38]
Distributed Oscillatory Guidance for Formation Flight of Fixed-Wing Drones
Y. Xu, J. Bautista, J. Hinojosa, HG de Marina · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
- [C37]
Versatile Distributed Maneuvering With Generalized Formations Using Guiding Vector Fields
Y. Lu, S. Luo, P. Zhu, W. Yao, HG de Marina, X. Zhang, and X. Xu · IEEE International Conference on Robotics and Automation (ICRA)
- [C36]
Inverse Kinematics on Guiding Vector Fields for Robot Path Following
Y. Zhou, J. Bautista, W. Yao, and HG de Marina · IEEE International Conference on Robotics and Automation (ICRA)
2024
- [J22]
Distributed Distance-based Formation-Motion Control of Unicycle Agents without Orientation Measurements
J. Chen, B. Jayawardhana, HG de Marina · Transactions on Control of Network Systems
Journal DOI - [J21]
Scaling up the formation of agents with heterogeneous sensing: mixed distance and bearing-only
J. Chen, B. Jayawardhana, HG de Marina · IEEE Transactions on Automatic Control
- [C35]
Resilient source seeking with robot swarms
A. Acuaviva, J. Bautista, W. Yao, J. Jiménez, HG de Marina · 63rd IEEE Conference on Decision and Control (CDC)
- [C34]
Behavioral-based circular formation control for robot swarms
J Bautista, HG de Marina · IEEE International Conference on Robotics and Automation (ICRA)
2023
- [J20]
Guiding vector fields for the distributed motion coordination of mobile robots
W. Yao, HG de Marina, Z. Sun, M. Cao · IEEE Transactions on Robotics, 39 (2), 1119-1135
- [J19]
Distributed formation control for manipulator end-effectors
H. Wu, B. Jayawardhana, H.G. de Marina, D. Xu · IEEE Transactions on Automatic Control, 68 (9), 5413-5428
- [C33]
Distance-based Formation-Motion Control for Unicycle Agents
J. Chen, B. Jayawardhana, HG de Marina · American Control Conference (ACC)
2022
- [J18]
Maneuvering Angle Rigid Formations with Global Convergence Guarantee
L. Chen; Z. Lin, HG de Marina, Z. Sun, F. Mir · IEEE/CAA Journal of Automatica Sinica, 9 (8), 1464-1475
- [J17]
Stabilizing and maneuvering angle rigid multi-agent formations with double-integrator agent dynamics
L. Chen, M. Shi, HG de Marina, M. Cao · IEEE Transactions on Control of Network Systems, 9 (3), 1362-1374
Journal DOI - [J16]
Stability Analysis of Gradient-Based Distributed Formation Control with Heterogeneous Sensing Mechanism: T he Three Robot Case
N Chan, B Jayawardhana, HG de Marina · IEEE Transactions on Automatic Control, 67 (8), 4285 - 4292
Journal DOI - [C32]
Energy-Aware Planning-Scheduling for Autonomous Aerial Robots
A. Seewald, HG de Marina, H. Skov, U. Pagh · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
2021
- [J15]
Forced Variational Integrators for the Formation Control of Multi-Agent Systems
L Colombo, HG de Marina · IEEE Transactions on Control of Network Systems, 8(3), 1336-1347
- [J14]
Singularity-free Guiding Vector Field for Robot Navigation
W.Yao, HG de Marina, B Lin, M.Cao · IEEE Transactions on Robotics, 37 (4), 1206-1221
- [J13]
Maneuvering formations of mobile agents using designed mismatched angles
L Chen, M Cao, HG de Marina · IEEE Transactions on Automatic Control, 67 (4), 1655-1668
Journal DOI - [J12]
Distributed formation maneuver control by manipulating the complex Laplacian
HG de Marina · Automatica, 132
- [J11]
Collaborative target-tracking control using multiple autonomous fixed-wing UAVs with constant speeds
Z Sun, HG de Marina, BDO Anderson, C. Yu · AIAA Journal of Guidance, Control, and Dynamics. 44(2), 238-250
- [J10]
Maneuvering and robustness issues in undirected displacement-consensus-based formation control
HG de Marina · IEEE Transactions on Automatic Control, 66 (7), 3370-3377
- [J9]
Angle-Constrained Formation Control for Circular Mobile Robots
N Chan, B Jayawardhana, HG de Marina · IEEE Control Systems Letters, 5 (1), 109-114
- [C31]
Leaderless collective motions in affine formation control
HG de Marina, J Jimenez, W Yao · 60th IEEE Conference on Decision and Control (CDC)
- [C30]
Distributed formation control of manipulators' end-effector with internal model-based disturbance rejection
Haiwen Wu, Bayu Jayawardhana, HG de Marina, Dabo Xu · 60th IEEE Conference on Decision and Control (CDC)
- [C29]
Distributed coordinated path following using guiding vector fields
W Yao, HG de Marina, Z Sun, M Cao · IEEE International Conference on Robotics and Automation (ICRA)
Nominated for Best Paper Award! Top 4 among 1946 accepted works out of 4005 submissions!
2020
- [C28]
Vector Field Guided Path Following Control: Singularity Elimination and Global Convergence
W Yao, HG de Marina, M Cao · 59th IEEE Conference on Decision and Control (CDC)
- [C27]
Forced variational integrator for distance-based shape control with flocking behavior of multi-agent systems
L Colombo, P Moreno, M Ye, HG de Marina, M Cao · 21st IFAC World Congress
2019
- [J8]
Circular formation control of multiple unicycle-type agents with non-identical constant speeds
Z Sun, HG de Marina, G Seyboth, BDO Anderson, C Yu · IEEE Transactions on Control Systems and Technology, 27 (1), 192-205
Journal DOI - [C26]
On the observability of relative positions in left-invariant multi-agent control systems and its application to formation control
L Colombo, HG de Marina, M Barbero, D Martin de Diego · 58th IEEE Conference on Decision and Control (CDC)
- [C25]
Triangular formation maneuver using designed mismatched angles
L Chen, M Cao, HG de Marina, B Jayawardhana, C Li · IEEE European Control Conference (ECC)
- [C24]
Flexible collaborative transportation by a team of rotorcraft
HG de Marina, E Smeur · IEEE International Conference on Robotics and Automation (ICRA)
2018
- [J7]
Distributed formation tracking using local coordinate systems
Q Yang, M Cao, HG de Marina, H Fang, J Chen · Systems & Control Letters. 111, 70-78
- [J6]
Quantization effects and convergence properties of rigid formation control systems with quantized distance measurements
Z Sun, HG de Marina, BDO Anderson, M Cao · International Journal of Robust and Nonlinear Control, 28 (16), 4865-4884
- [J5]
Taming Mismatches in Inter-agent Distances for the Formation-Motion Control of Second-Order Agents
HG de Marina, B Jayawardhana, M Cao · IEEE Transactions on Automatic Control, 63 (2), 449-462
- [C23]
On the stability and applications of distance-based flexible formations
HG de Marina, Z Sun, S Mou · 57th IEEE Conference on Decision and Control (CDC)
- [C22]
Multi-robot motion-formation distributed control with sensor self-calibration: experimental validation
HG de Marina, J Siemonsma, B Jayawardhana, M Cao · 15th International Conference on Control, Automation, Robotics and Vision (ICARCV)
Nominated for Best Paper Award! Top 5 among 300+ accepted works
- [C21]
A Variational Integrator for the distance-based formation control of multi-agent systems
L Colombo, HG de Marina · 7th IFAC Workshop on Distributed and Control in Networked Systems
Conference DOI
2017
- [C20]
Development of A Fixed-Wing mini UAV with Transitioning Flight Capability
M Bronz, E Smeur, HG de Marina, G Hattenberger · 35th AIAA Applied Aerodynamics Conference
- [C19]
System simulation of a fleet of drones to probe cumulus clouds
Rafael Bailon-Ruiz, Christophe Reymann, Simon Lacroix, Gautier Hattenberger, HG de Marina, Fayçal Lamraoui · International Conference on Unmanned Aircraft Systems
Conference DOI - [C18]
Circular formation control of fixed-wing UAVs with constant speeds
HG de Marina, Z Sun, M Bronz, G Hattenberger · International Conference on Intelligent Robots and Systems (IROS)
- [C17]
In-Flight Thrust Measurement using On-Board Force Sensor
M Bronz, HG de Marina, G Hattenberger · AIAA Atmospheric Flight Mechanics Conference
Conference DOI - [C16]
Guiding Vector Field Algorithm for a Moving Path Following Problem
Y Kapitanyuk, HG de Marina, A Proskurnikov, M Cao · 20th World Congress of the International Federation of Automatic Control (IFAC)
Conference DOI - [C15]
Distributed algorithm for controlling scale-free polygonal formations
HG de Marina, B Jayawardhana, M Cao · 20th World Congress of the International Federation of Automatic Control (IFAC)
- [C14]
Controlling a triangular flexible formation of autonomous agents
HG de Marina, Z. Sun, M. Cao, and B. D. O. Anderson · 20th World Congress of the International Federation of Automatic Control (IFAC)
- [C13]
Guidance algorithm for smooth trajectory tracking of a fixed wing UAV flying in wind flows
HG de Marina, YA Kapitanyuk, M Bronz, G Hattenberger, M Cao · IEEE International Conference on Robotics and Automation (ICRA)
2016
- [J4]
Distributed Rotational and Translational Maneuvering of Rigid Formations and Their Applications
HG de Marina, B Jayawardhana, M Cao · IEEE Transactions on Robotics, 32 (3), 684-696
- [C12]
Distributed scaling control for rigid formations
HG de Marina, B Jayawardhana, M Cao · IEEE 55th Conference on Decision and Control (CDC) 5140 - 5145
- [C11]
On the Role and Compensation of Distance Mismatches in Rigid Formation Control for Second-Order Agents
HG de Marina, B Jayawardhana, M Cao · IFAC-PapersOnLine 49 (18), 398-403 (NOLCOS)
- [C10]
Quantization effects in rigid formation control
Z. Sun, HG de Marina, B. D. O. Anderson, and M. Cao · 6th Australian Control Conference (AUCC) 2016, Newcastle, Australia
Conference DOI
2015
- [J3]
Controlling Rigid Formations of Mobile Agents Under Inconsistent Measurements
HG de Marina, M Cao, B Jayawardhana · IEEE Transactions on Robotics 31 (1), 31-39
2014
- [C9]
Controlling triangular formations of autonomous agents in finite time using coarse measurements
H Liu, HG de Marina, M Cao · IEEE International Conference on Robotics and Automation (ICRA), 3601-3606
Conference DOI
2013
- [C8]
Controlling Formation of Autonomous Agents with Distance Disagreements
HG de Marina, M Cao, B Jayawardhana · Estimation and Control of Networked Systems (NECSYS) 4 (1), 411-416
Conference DOI - [C7]
Optimization-based worst-case analysis of a launcher during the atmospheric ascent phase
A Marcos, HG De Marina, V Mantini, C Roux, S Bennani · AIAA Guidance, Navigation, and Control Conference and Exhibit
Conference DOI
2012
- [J2]
Adaptive UAV attitude estimation employing unscented kalman filter, FOAM and low-cost MEMS sensors
HG de Marina, F Espinosa, C Santos · Sensors 12 (7), 9566-9585
- [J1]
UAV attitude estimation using unscented Kalman filter and TRIAD
HG de Marina, FJ Pereda, JM Giron-Sierra, F Espinosa · IEEE Transactions on Industrial Electronics, 59 (11), 4465-4474
- [C6]
Angle of Attack and True Airspeed failure sensor detection and recovery based on Unscented Kalman Filters for the ALPHA vehicle
HG de Marina, A Marcos, R Haya · Fault Detection, Supervision and Safety of Technical Processes 8 (1), 1197-1202
2011
- [C5]
Towards automatic oil spill confinement with autonomous marine surface vehicles
FJ Pereda, HG de Marina, JM Giron-Sierra, J Jimenez · OCEANS IEEE-Spain
Conference DOI
2010
- [C4]
Developing an Autonomous Surface Ship for Sea Demining
JM Giron-Sierra, F Pereda, HG de Marina, S Cifuentes · IFAC Proceedings Volumes 43 (20), 91-96
Conference DOI - [C3]
Path planning combined with fuzzy control for autonomous ships
HG de Marina, FJ Pereda, JM Girón-Sierra · IEEE International Conference on Computational Intelligence for Measurement Systems and Applications
Conference DOI - [C2]
Sea demining with autonomous marine surface vehicles
FJ Pereda, HG de Marina, JF Jiménez, JM Giron-Sierra · IEEE Safety Security and Rescue Robotics
Conference DOI - [C1]
A development project of autonomous marine surface vehicles for sea demining
FJ Pereda, HG de Marina, JF Jiménez, JM Giron-Sierra · 11th International Conference on Control Automation Robotics & Vision
Conference DOI
Tech notes
- [T2]
SO(3) attitude controllers and the alignment of robots with non-constant 3D vector fields
J. Bautista, HG de Marina · arXiv
In constant development as part of the research on geometric control of robot swarms
- [T1]
Securing Isosceles Triangular Formations under Heterogeneous Sensing and Mixed Constraints
N Chan, B Jayawardhana, HG de Marina · arXiv