SWARM SYSTEMS LAB.
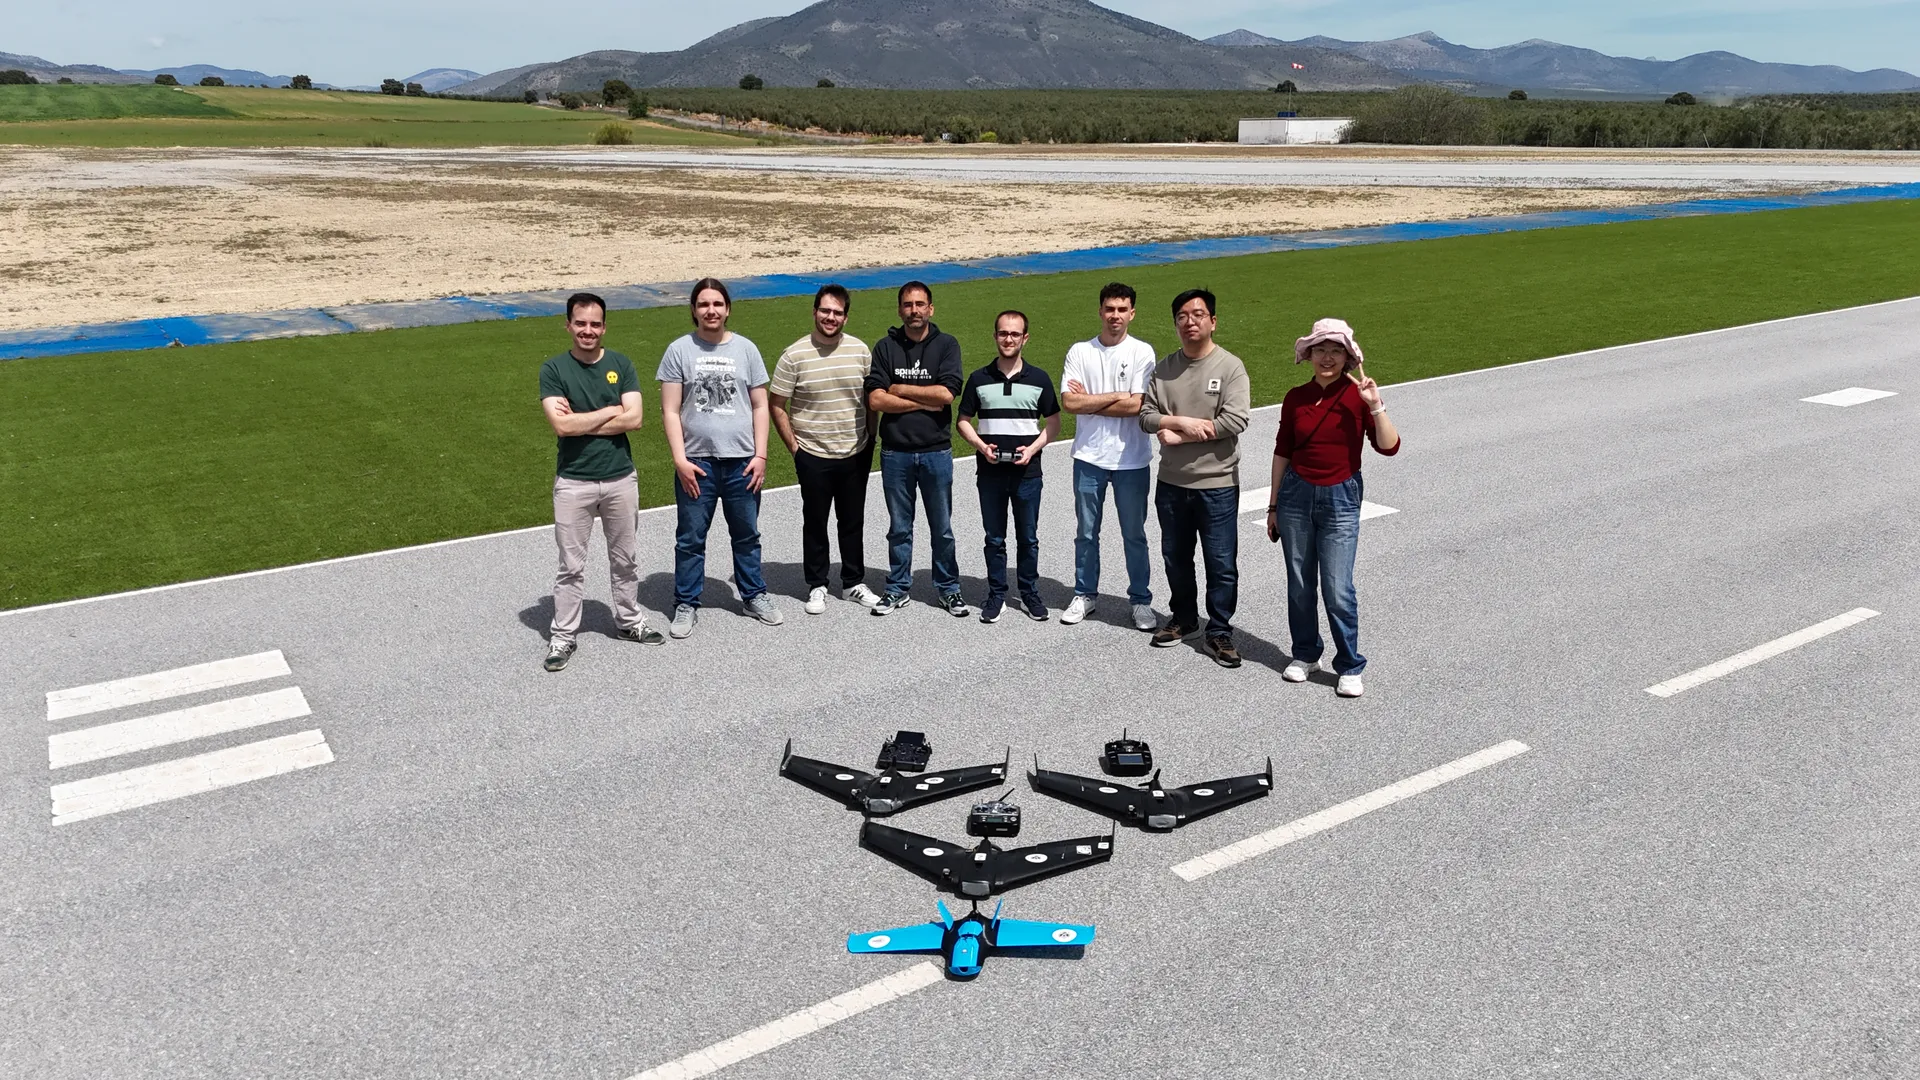
In the Swarm Systems Lab we are intrigued by the realm of swarm robotics and autonomous systems, where control theory and emergent behaviour converge. We work on formal guarantees for distributed coordination, and we fly them: swarms of fixed-wing aircraft, rotorcraft, rovers, and other autonomous robots.
Our institutions and funders
Find us elsewhere
-

GitHub
Our code in the open. The Swarm Systems Lab's Python simulation environment used for the numerical validation of our published work.
Open GitHub → -

YouTube
Field footage, conference presentations, and research videos from the lab.
Open YouTube → -

Discord
Whether you are a seasoned researcher or just starting to explore swarm robotics, join us on Discord to exchange ideas, discuss research, and share experiences on autonomous swarms.
Open Discord →
From the field
- 2026-08-01
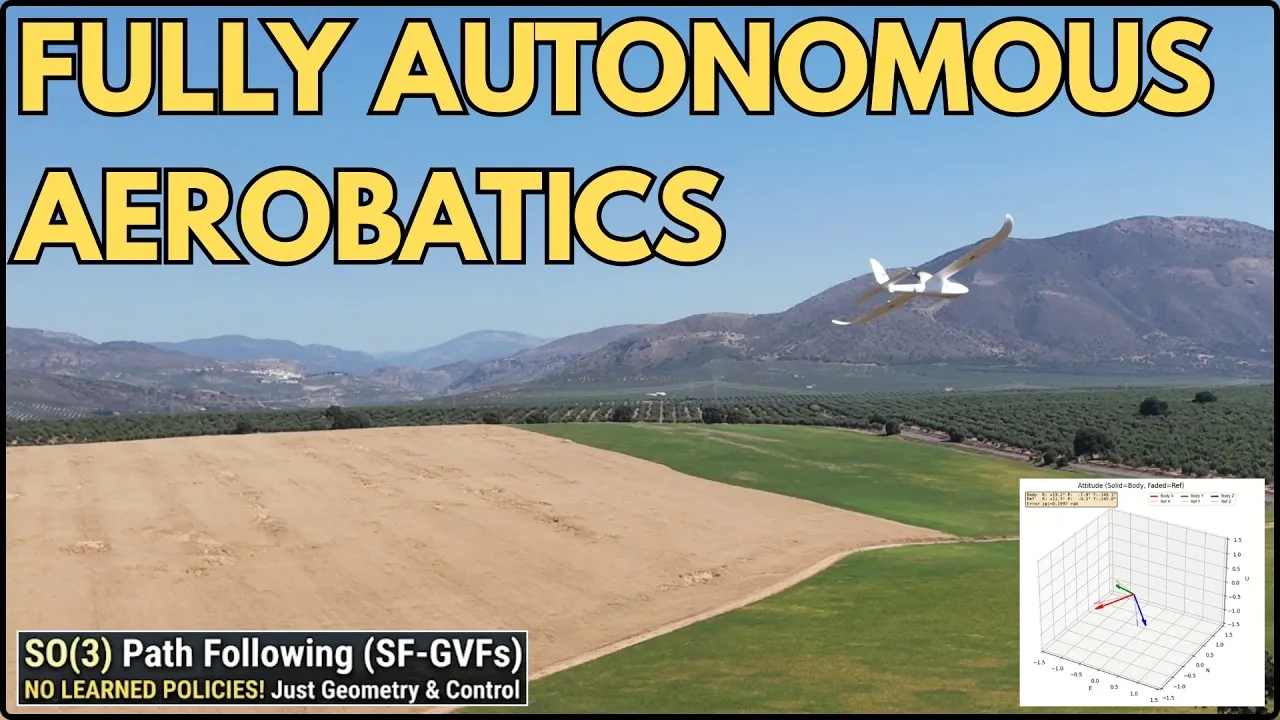
Fully autonomous Fixed-wing aerobatics (without GPS)
- 2025-08-12
Two fixed-wing drones rendezvous, fly in formation, split, and meet again
- 2025-07-27
3D square formation with four flying wings
- Seminar on guiding vector fields at Dalian University of Technology
Jesús Bautista and Hector G. de Marina visited Dalian University of Technology in China, where we gave a seminar on how to construct guiding vector fields for the control of aerobatics and other complex behaviors beyond…
- Martin Zoula is visiting us this October
Martin Zoula is visiting the Swarm Systems Lab for the whole month of October. He comes from the Multi-robot Systems (MRS) group at the Czech Technical University in Prague, and his PhD focuses on drone communications.
- Diego Vela gives a talk on guiding vector fields at the University of Zaragoza
Our Ph.D. student Diego Vela Calcerrada gave a talk at the University of Zaragoza (Unizar) on guiding vector fields for multi-robot coordination.
- Welcome to our new website!
After years on Google Sites we have rebuilt it from scratch. The old one had served its purpose, but it had grown rusty: slow to load, awkward to lay out, and enough of a chore to update that news tended to pile up…